
Application area
LiDAR application solutions for robotics
Connect distance sensing to mounting, control logic, and field validation for robot obstacle avoidance, drop prevention, logistics, and positioning tasks.
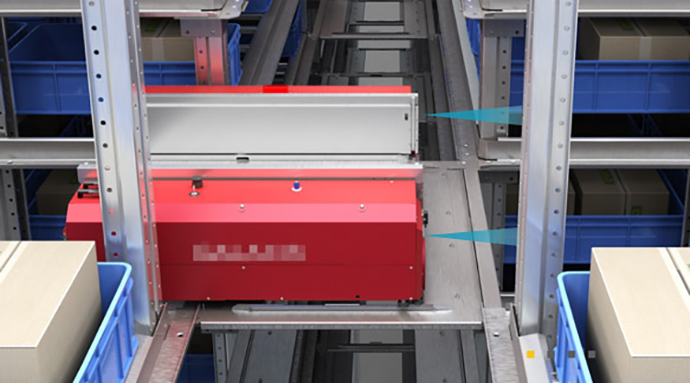
Mobile robots need to detect obstacles, floor edges, and available travel distance from constrained mounting positions. Sensor output is only one system input: coverage, blind zones, speed, braking logic, floor materials, and controller behavior determine the final result.
Common engineering problems
- Mounting height and orientation must cover the real hazard zone without structural occlusion.
- Detection range must be designed with speed, deceleration, control latency, and safety margin.
- Dark targets, direct light, reflective floors, dust, and cross-interference require field validation.
- Obstacle avoidance, drop prevention, and navigation are different tasks and cannot share one unverified threshold.
Capability overview
- Provide direct forward- or downward-looking distance input.
- Match current products by range, space, interface, and environment.
- Connect product resources, recommendation limits, and FAQs to each task.
Choose an application solution
AGV/AMR obstacle avoidance focuses on forward hazards and stopping; robot drop prevention focuses on floor discontinuities; smart logistics covers short-to-medium-range perception for delivery and logistics robots.
Shuttle vehicle obstacle avoidance
Provide forward obstacle distance in warehouse aisles and connect it to slowdown zones and stopping logic.
→Robot drop prevention and obstacle avoidance
Use downward floor distance and forward obstacle distance as separate inputs for robot slowdown and stop actions.
→Assistive-device ranging
Provide forward or downward range input in an assistive device, with TF-Luna as the featured sensor.
→Smart logistics and last-mile delivery
Provide short-to-medium-range distance input for logistics and delivery robots to support aisle sensing, approach decisions, slowdown, and stopping.
→Overhead crane positioning and obstacle avoidance
Provide long-range position or separation input for overhead cranes to support travel zones, slowdown, and obstacle-avoidance logic.
→Need help choosing a solution in this area?
Share your task conditions, operating environment, and system constraints. Our engineering team can help identify the right solution.