
Scenario
Application scenario
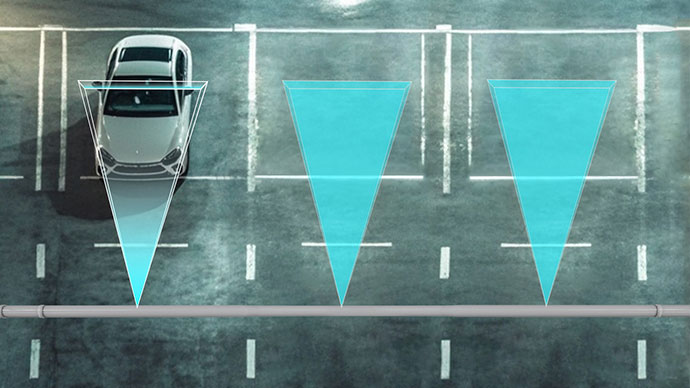
A smart-parking system can monitor distance from above or the side, then let a controller determine occupancy and trigger a camera or report status. Vehicle types, angle, and outdoor light require site calibration.
Engineering problem
- Empty pavement, vehicle types, and parking position produce different distances.
- Sunlight, weather, contamination, and mounting error affect returns.
- Distance changes need thresholds, duration, and fault handling before becoming an occupancy event.
Why LiDAR
LiDAR provides direct distance change so a controller can trigger a camera or update occupancy when a vehicle arrives, reducing continuous processing.
Workflow
- Define bay coverage, mounting height, and vehicle range.
- Record distance distributions for empty and occupied states.
- Configure thresholds, duration, debounce, and fault handling.
- Validate sunlight, rain or snow, contamination, and off-center parking.