Products3D LiDAR

LR10 series

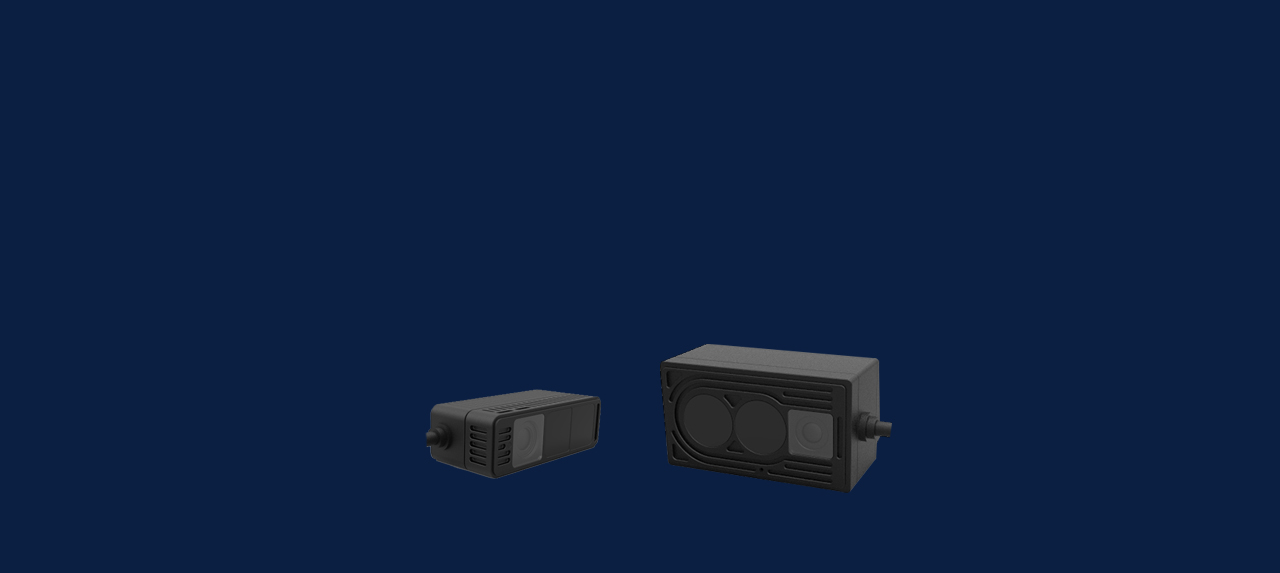
LR10 seriesshort-range LiDAR Camera fusion sensor

LR10 series supplies near-field point clouds and RGB for mobile-robot spatial sensing and data capture for warehouse object shape and volume measurement.

Key specifications

Measuring range
0.05-18m
Frame rate
10fps
Interface
Ethernet,GMSL,I/O
Protection
IP67

Need help confirming a selection or purchase details?

Full specifications

Product technical specifications
ParameterValueParameterValue
Measuring range0.05-18mDetecting accuracy≤3cm
Frame rate10fpsInterfaceEthernet,GMSL,I/O
ProtectionIP67Dimensions92 mm × 47 mm × 51 mm
Weight460gField of view70°×120°
Output dataPoint cloud&RGBOperating voltage24V

Applicable scope and usage limits

Applicable scenarios

  • Evaluate LR10 when a mobile robot must observe nearby objects at different heights or a warehouse system needs package surface geometry.
  • Point clouds and RGB feed downstream occupancy analysis, object analysis or volume calculation.

Conditions

  • Confirm the selected series model, interface and mounting orientation, then validate field coverage, occlusion, calibration and algorithms.
  • Full-object measurement also depends on visibility of the required surfaces.

Not applicable scenarios

  • For one proximity threshold or distance value, compare smaller single-point or line-beam products.
  • For distant 3D targets, compare long-range 3D LiDAR.
  • Sensor ranging accuracy does not directly specify calculated volume accuracy.

3D sensing: nearby surfaces versus distant spatial targets

Nearby package or robot-surround surface data and distant 3D targets are different selection tasks. Define distance, target size and required information, then assess field coverage, interfaces, computing and platform load. Compare 2D when a planar contour is sufficient.

View comparison topic
AD2-S-X3

Distant 3D targets on a capable host platform

Compare AD2-S-X3 for more distant 3D positions and scene structure when power, automotive Ethernet and point-cloud processing are available.

Boundary: It is not a direct substitute for ordinary Ethernet equipment. Check field, resolution and rate by mode, plus platform power and payload.

View model details
LR10 seriesCurrent model

Nearby surfaces, occupancy and volume data capture

Compare LR10 series when nearby point clouds and RGB feed package-shape or robot-surround object analysis.

Boundary: Check interface and mounting for the specific model. Volume or people-count results also depend on coverage, calibration and downstream algorithms.

View model details
Key parameter comparison
ParameterAD2-S-X3LR10 series
Output data3D Point CloudPoint cloud&RGB
Measuring range300 m @ 10%0.05-18m
Field of view120° × 28°70°×120°
Frame rate10 Hz10fps
Detecting accuracy5 cm @ 1 σ≤3cm
Interface1000Base-T1 Automotive EthernetEthernet,GMSL,I/O
ProtectionIP67 & IP6K9KIP67
Dimensions49 mm × 160 mm × 144 mm92 mm × 47 mm × 51 mm
Weight1.2 kg460g
Power consumption≤ 15 W—
Operating voltage9 ~ 32 V24V

Product inquiry

Talk to a product specialist

Tell us what you need and our team will get back to you.

Product inquiry

Inquiry sent

Your inquiry has been received. We will be in touch soon.