
Scenario
Application scenario
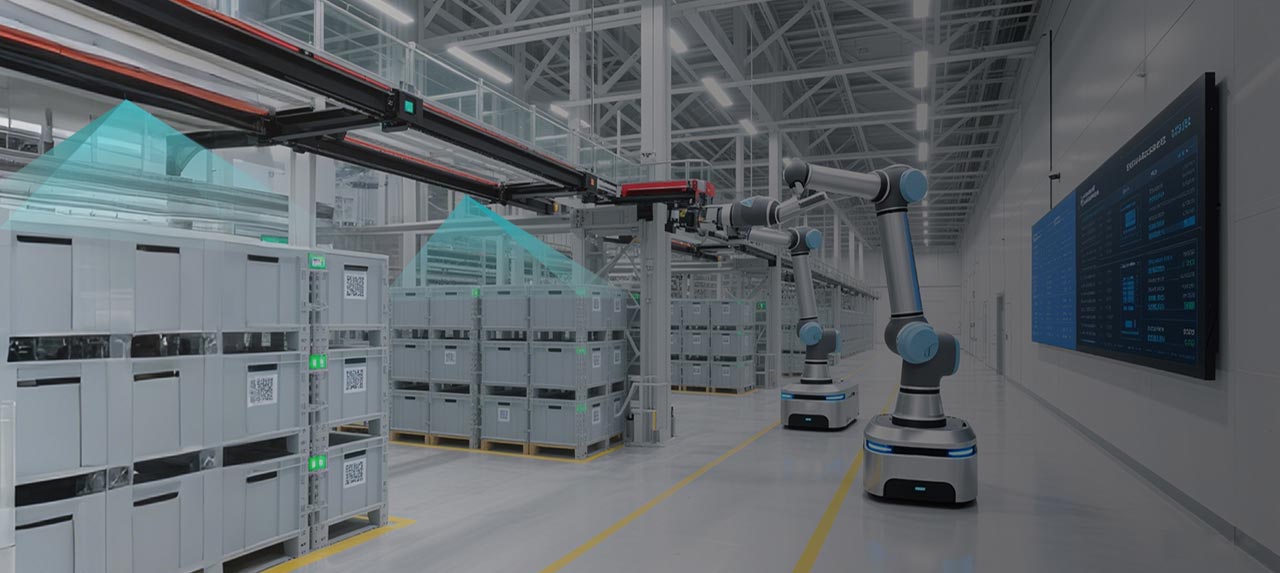
Volume is not a single distance. The system must cover the surface, establish coordinates and an empty reference, then handle occlusion, edges, and outliers in a separate algorithm.
Engineering problem
- A single point distance does not provide three-dimensional volume.
- Occlusion, edges, and irregular surfaces affect reconstruction.
- Sensor count, scan coverage, and reference coordinates define the measurable area.
Why LiDAR
Multi-point or scanning LiDAR provides spatial surface-distance data for a volume algorithm; calibration and software generate the final volume.
Workflow
- Define the measurement zone, smallest/largest object, and allowed occlusion.
- Design sensor count, position, coverage, and coordinate reference.
- Capture empty and loaded data for calibration, filtering, and reconstruction.
- Validate algorithm error and maintenance interval with known-volume objects.