
A19
马里兰大学 + 代尔夫特理工大学 · EVPropNet
TFMini
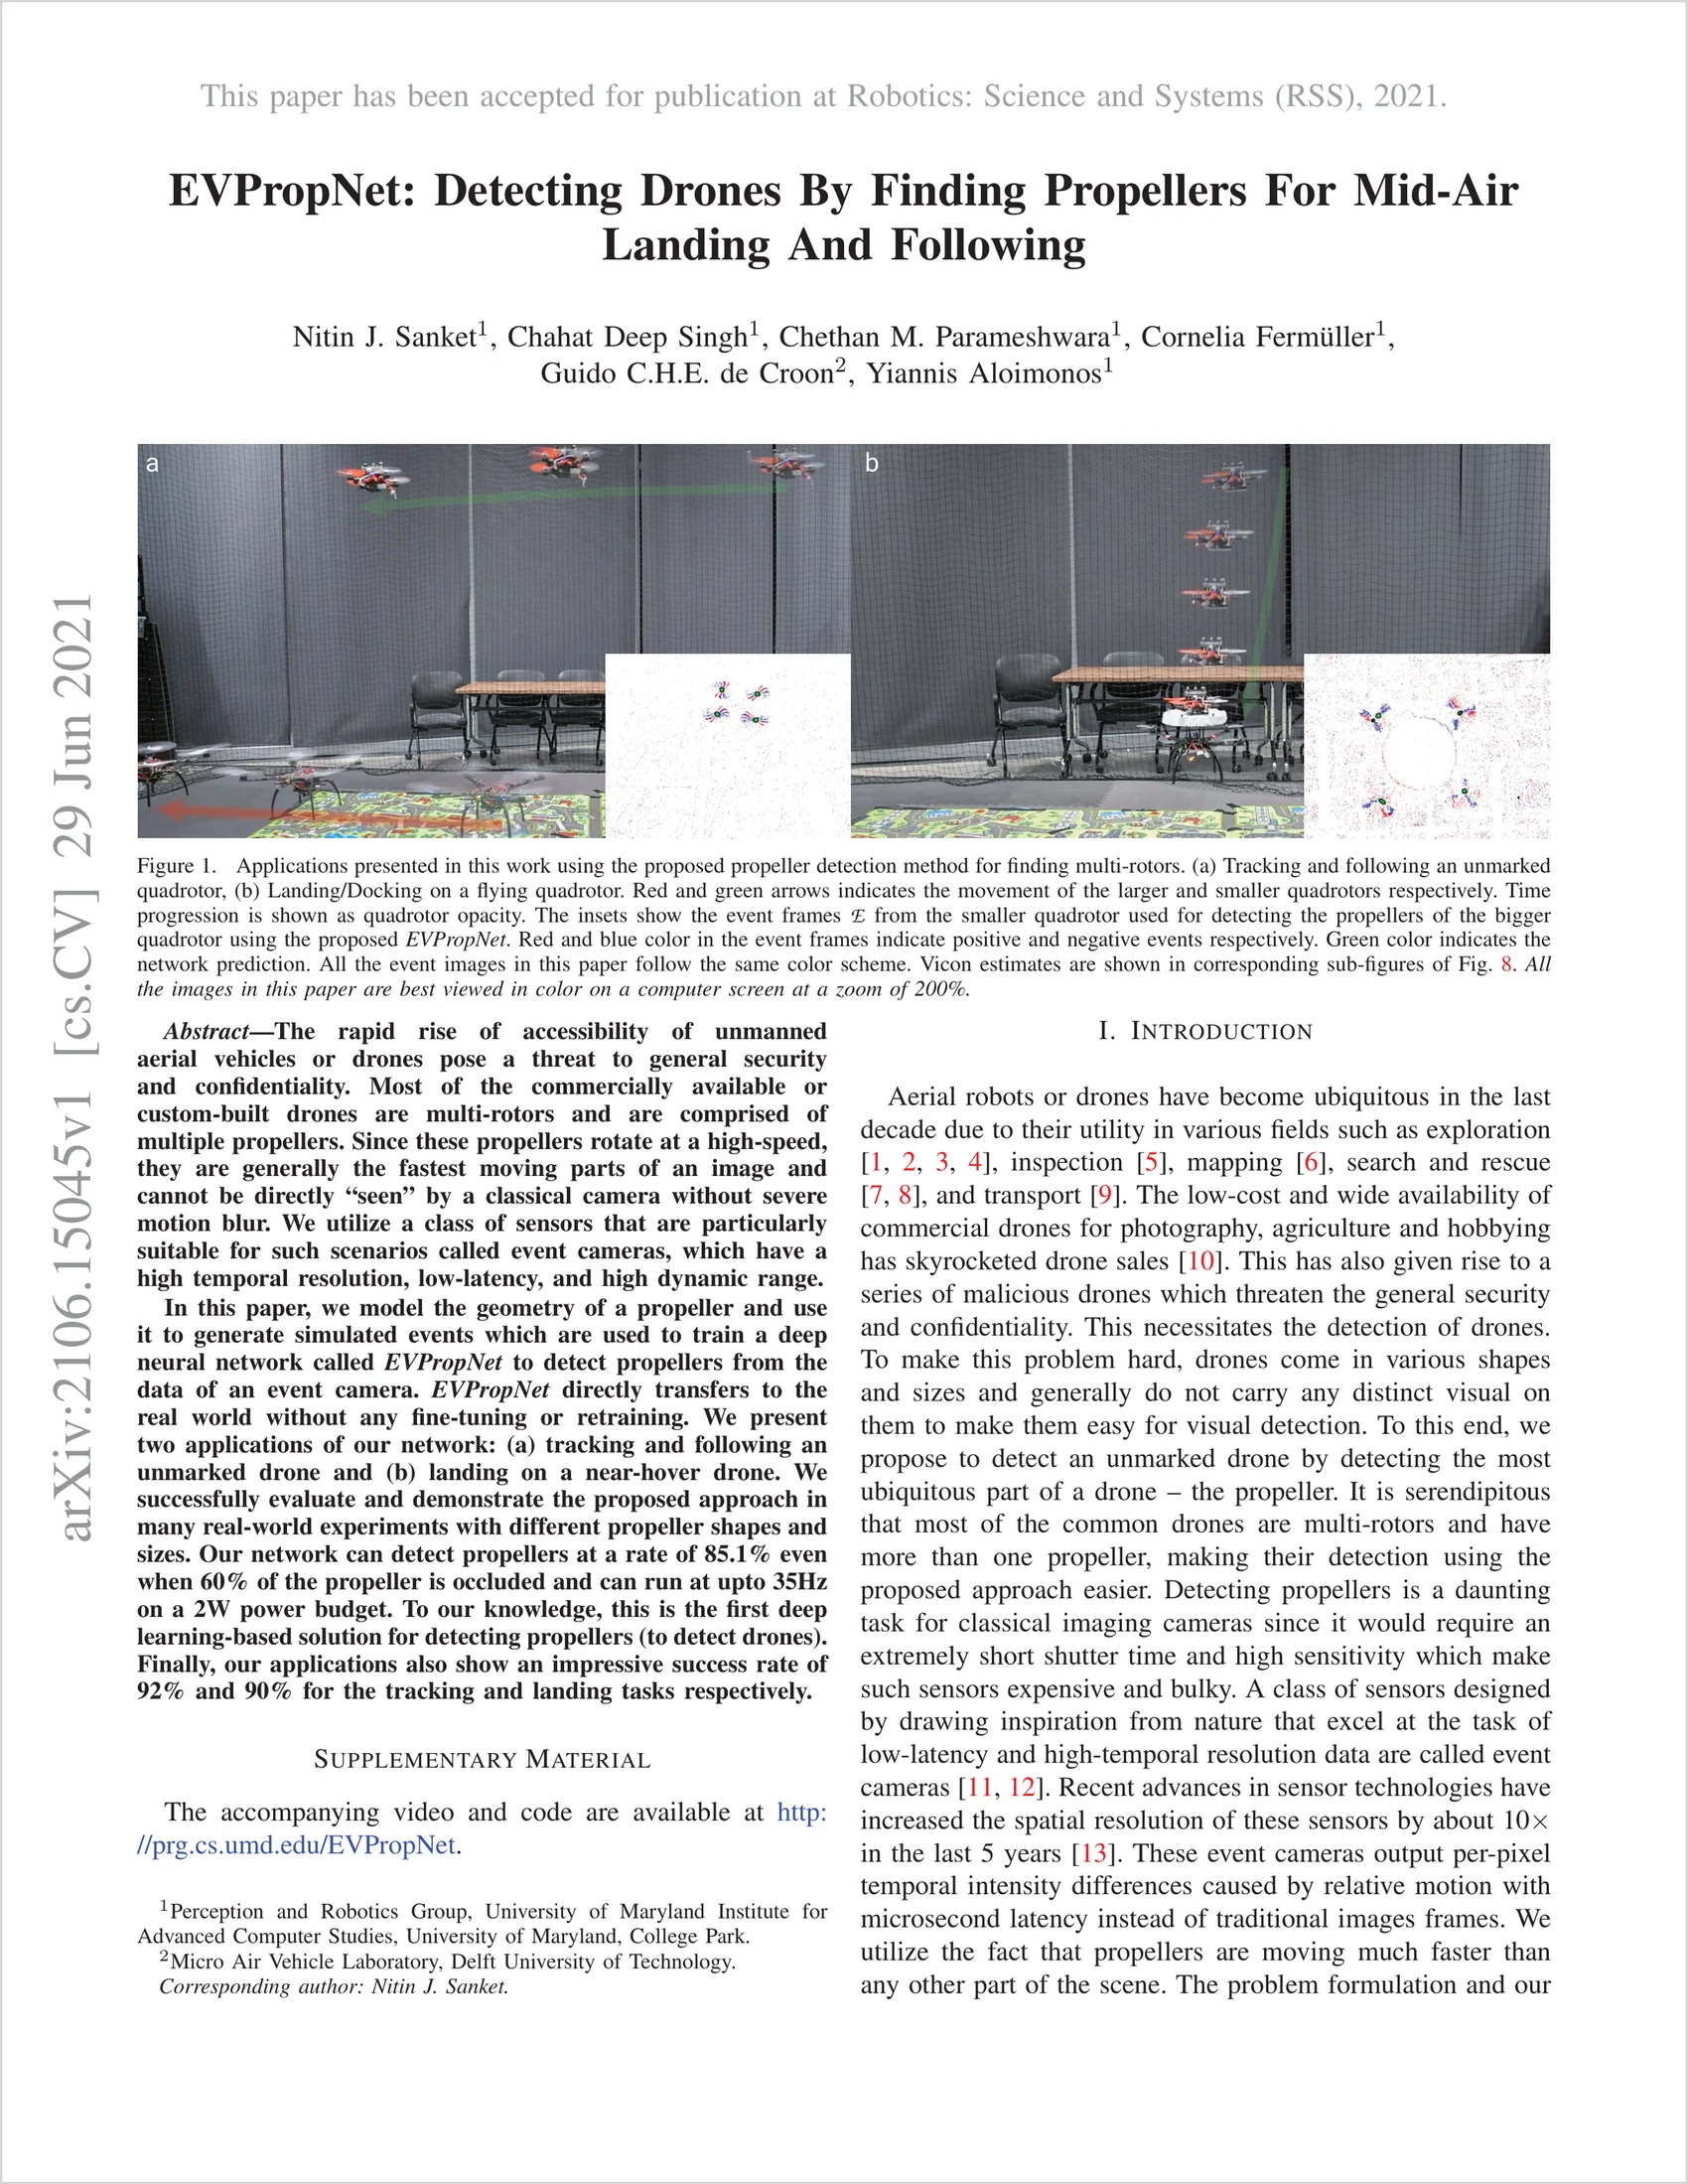
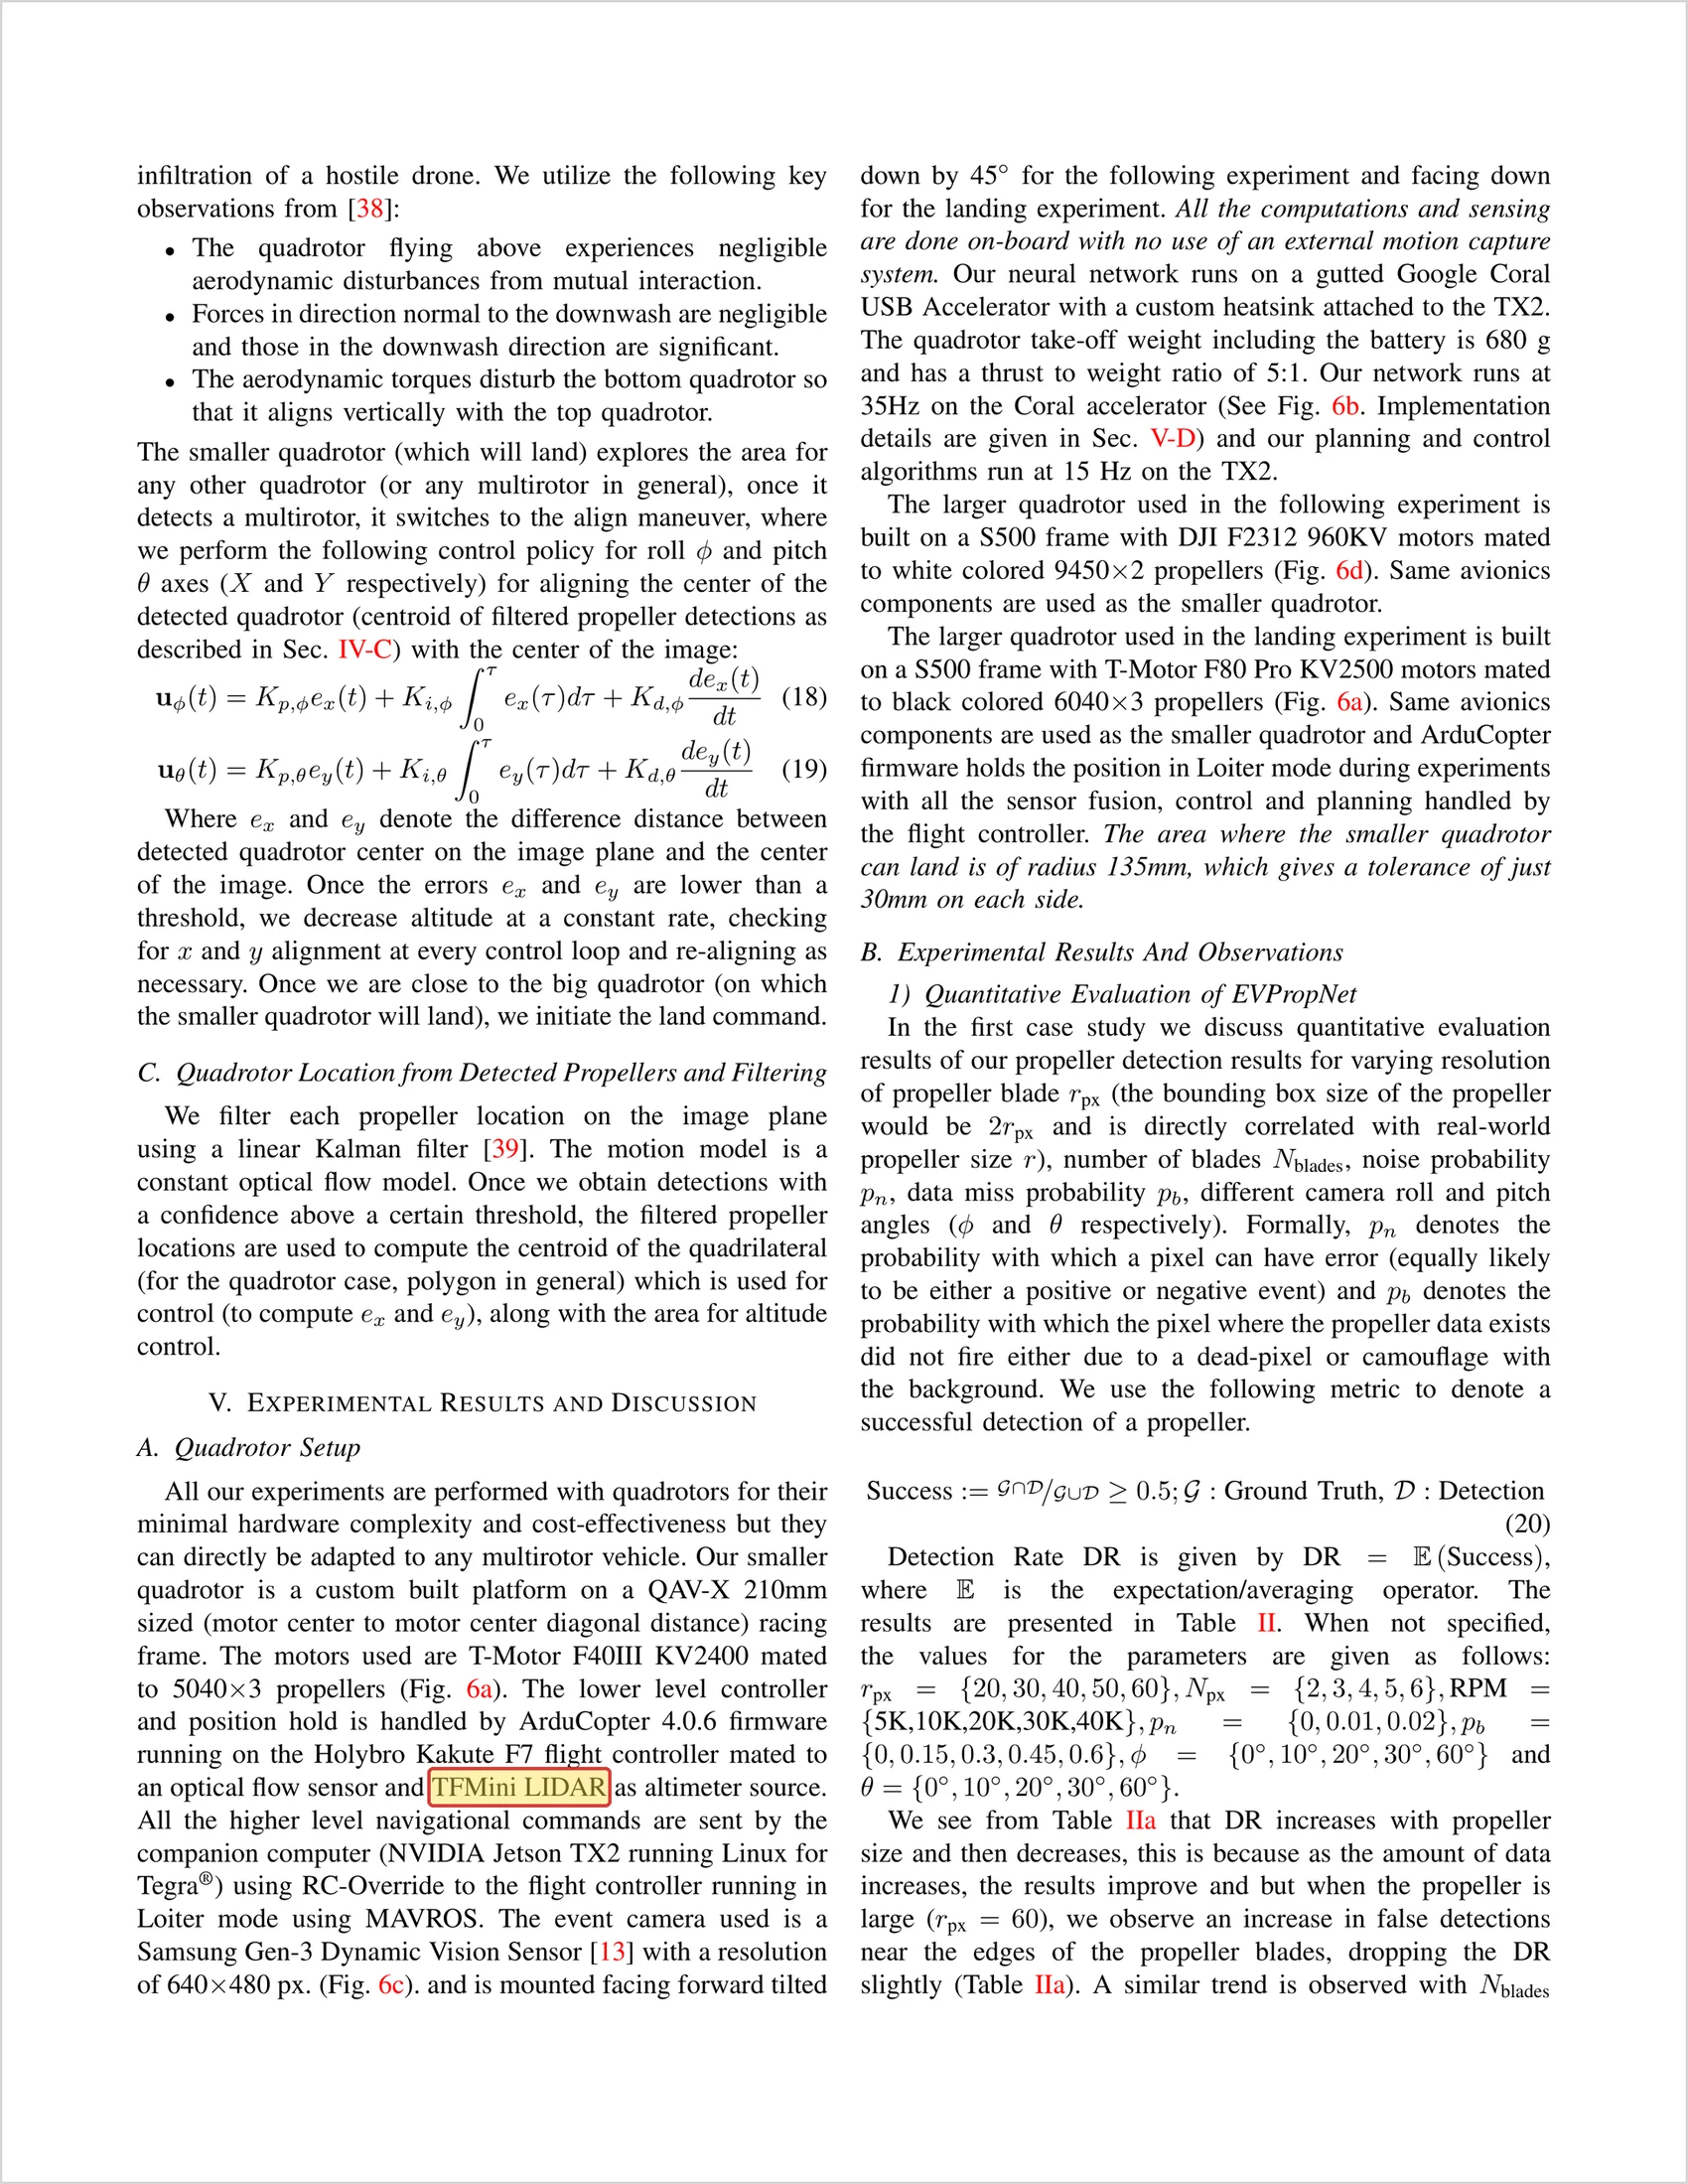
The lower level controller and position hold is handled by ArduCopter 4.0.6 firmware running on the Holybro Kakute F7 flight controller mated to an optical flow sensor and TFMini LIDAR as altimeter source.
来源
- EVPropNet: Detecting Drones By Finding Propellers For Mid-Air Landing And Following
Nitin J. Sanket, Chahat Deep Singh, Chethan M. Parameshwara, Cornelia Fermüller, Guido C.H.E. de Croon, Yiannis Aloimonos; Robotics: Science and Systems XVII, 2021; DOI 10.15607/RSS.2021.XVII.074. Licensed under CC BY 4.0. Full pages reproduced; transparent source-passage highlights added to the supplied evidence page. CC BY 4.0 - EVPropNet: Detecting Drones By Finding Propellers For Mid-Air Landing And Following · arXiv:2106.15045v1
Nitin J. Sanket, Chahat Deep Singh, Chethan M. Parameshwara, Cornelia Fermüller, Guido C.H.E. de Croon, Yiannis Aloimonos; Robotics: Science and Systems XVII, 2021; DOI 10.15607/RSS.2021.XVII.074. Licensed under CC BY 4.0. Full pages reproduced; transparent source-passage highlights added to the supplied evidence page. CC BY 4.0