TF-Luna (underwater) Datasheet
TF-Luna (underwater) Datasheet, including the parameters, figures and instructions in the original document.
TF-Luna-UW is a single-point Time-of-Flight (ToF) LiDAR, using an 850nm infrared light source and a unique optical and electrical design for stable, precise, and highly sensitive distance measurement. Highly adaptable to various environments and targets, it's ideal for outdoor pool robots, even in direct sunlight.
Advantages: Compact size, high accuracy, low power consumption, and algorithms optimized for underwater applications.
Applications: Pool edge mapping, underwater obstacle avoidance, and pool step detection.
Technical Specifications
| Underwater Measurement Performance | |
|---|---|
| Detection range | 10cm~55cm①,in clear water |
| Accuracy | <±3 cm① |
| Repeatability | < ±1 cm① |
| Distance resolution | 1cm |
| Default frame rate② | 100Hz |
| Optical Parameters | |
| Light source | VCSEL |
| Central wavelength | 850nm |
| FoV of laser emission③ | 2° |
| Eye safety | Class 1 Eye-safe[EN60825] |
| Mechanical/Electrical | |
| Power supply | DC 3.7V~5.2V |
| Average power consumption | ≤70mA |
| Power consumption | ≤0.35W |
| Peak current | 150mA |
| Storage temperature | -20℃~75℃ |
| Communication level | LVTTL(3.3V) |
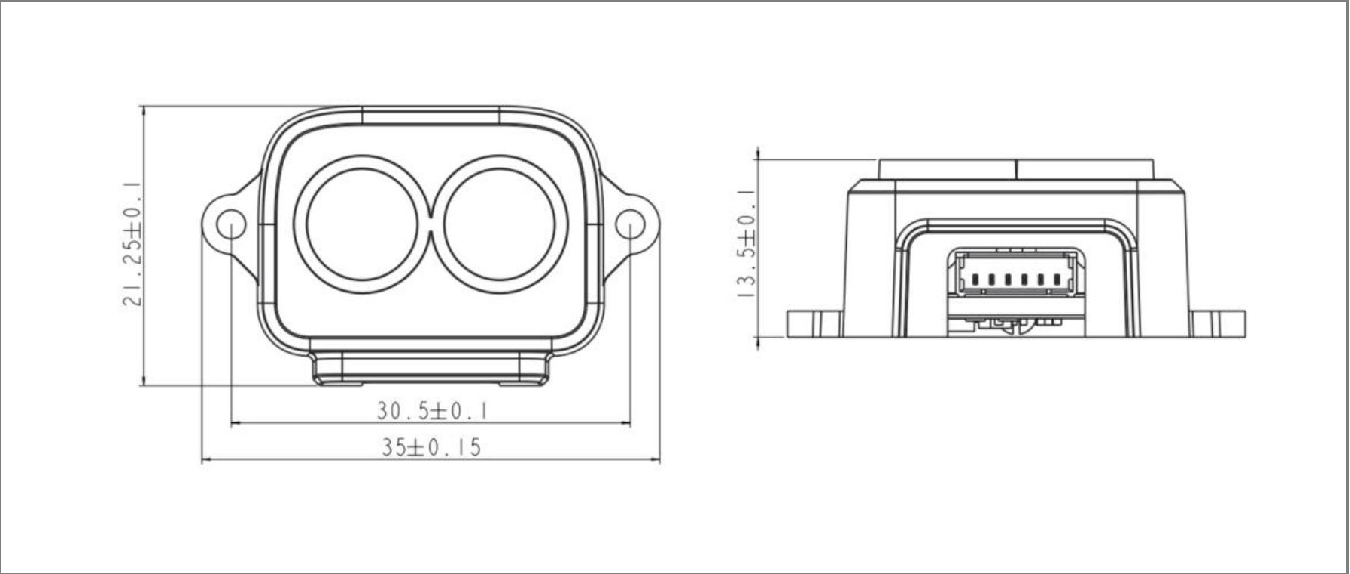
| Dimensions | 35mm*21.25mm*13.5mm |
| Weight | <5g |
| Chassis material | PC/ABS | |||
|---|---|---|---|---|
| Cable length | 10cm | |||
| Communication Protocol④ | ||||
| UART | I2C | |||
| Baud rate | 115200 (Adjustable) | Maximum transfer rate | 400kbps | |
| Data bit | 8 | Master-follower mode | Follower mode | |
| Stop bit | 1 | Default address | 0x10 | |
| Parity | None | Address range | 0x01~0x7F | |
| Dimensions(Unit: mm) | ||||
 |
||||