ProductsSingle-point LiDAR

TF-UW500

TF-UW500Underwater Single-Point LiDAR

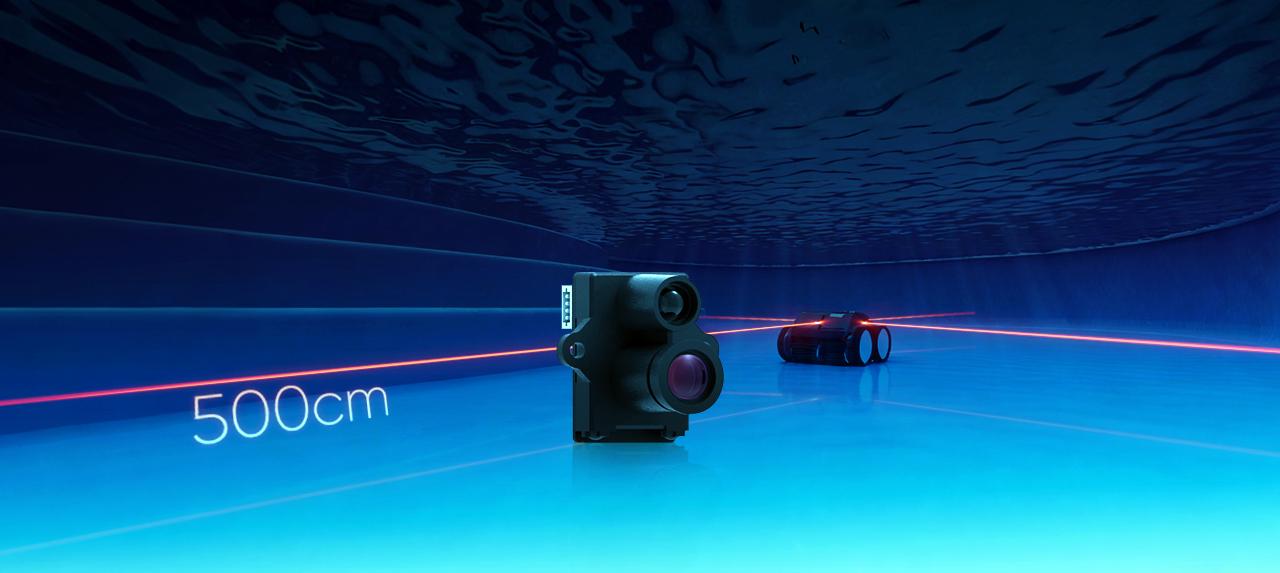
TF-UW500 supports directional short-range measurement in underwater equipment such as pool robots, with a small, lightweight module for embedded integration.

Key specifications

Measuring range
> 5 m
Frame rate
20Hz
Interface
UART,I²C
Protection
without enclosure

Need help confirming a selection or purchase details?

Full specifications

Product technical specifications
ParameterValueParameterValue
Measuring range> 5 mDetecting accuracy< 3 cm (0.1 ~ 2m)
Frame rate20HzInterfaceUART,I²C
Protectionwithout enclosureDimensions24mm×16mm ×20.4mm
Power consumption≤ 0.5 WWeight< 5 g
Field of view< 0.5°Output data3.3 V TTL
Operating voltageDC 5±0.2 V

Applicable scope and usage limits

Applicable scenarios

  • Evaluate TF-UW500 when underwater equipment needs the distance to a wall or obstacle ahead and has tight space and weight limits.
  • Its directional range can support local proximity detection on a pool robot.

Conditions

  • The host system must provide a suitable optical window, mounting and sealing.
  • Water clarity, bubbles, target surface and the installed optical path determine usable range.

Not applicable scenarios

  • For surrounding wall contours used in localization, compare underwater scanners such as VLS-H5.
  • For turbid-water or longer-range underwater tasks, also evaluate acoustic sensing suited to that water environment.
  • One distance value does not provide complete pool navigation.

FAQ

What is the measurement range of the TF-UW500 underwater?

The TF-UW500 achieves a detection range exceeding 5 meters underwater at standard conditions (NTU < 0.5, 30% reflectivity, perpendicular beam incidence, water depth > 1 m). It has a blind zone of ≤ 0.1 m, making it unsuitable for very close-range targets beneath that threshold.

What communication interfaces does the TF-UW500 support?

The TF-UW500 supports both UART and I²C interfaces, switchable by command. The default UART baud rate is 115200 (configurable), with 8 data bits, 1 stop bit, and no parity, using a 1.0 mm 4-pin connector (HC-1.0-4PWT) and 3.3 V TTL logic levels.

Which tasks suit TF-UW500, and why choose it?

Evaluate TF-UW500 when underwater equipment needs the distance to a wall or obstacle ahead and has tight space and weight limits. Its directional range can support local proximity detection on a pool robot.

What are the accuracy and repeatability specifications of the TF-UW500?

Within the 0.1–2 m range, the TF-UW500 offers accuracy better than 3 cm and repeatability better than 1 cm at 1σ confidence interval. The distance resolution is 1 mm, enabling precise underwater measurements for robotic navigation and level monitoring applications.

What is the operating temperature range and environmental rating?

The TF-UW500 operates between 0 °C and +50 °C, with a storage temperature range of −20 °C to +70 °C. Note that it has no IP rating specified in the datasheet; waterproofing specifications should be confirmed with Benewake technical personnel before deployment in wet environments.

What power supply does the TF-UW500 require?

The TF-UW500 requires a DC 5±0.2 V power supply with average consumption of less than 500 mA (5 V × 100 mA). Peak inrush current at startup can reach 700 mA, so adequate power supply capacity with transient margin is recommended for stable operation.

What are the physical dimensions and weight of the TF-UW500?

The TF-UW500 measures 24.0 mm × 16.0 mm × 20.4 mm and weighs less than 5 grams excluding cables. These compact dimensions make it well-suited for integration into space-constrained robotic platforms and subsea equipment.

When should an alternative to TF-UW500 be considered?

For surrounding wall contours used in localization, compare underwater scanners such as VLS-H5. For turbid-water or longer-range underwater tasks, also evaluate acoustic sensing suited to that water environment. One distance value does not provide complete pool navigation. The host system must provide a suitable optical window, mounting and sealing. Water clarity, bubbles, target surface and the installed optical path determine usable range.

How should TF-UW500 be compared with other models or sensing approaches?

The underwater optical application distinguishes TF-UW500 from land-based single-point sensors; directional range distinguishes it from VLS-H5 scanning. Compare the required information and host integration rather than land-based headline ranges or unverified competitor claims.

What platforms and systems can the TF-UW500 integrate with?

The TF-UW500's UART and I²C interfaces enable integration with Arduino, PLC, embedded Linux systems, and ROS-based robotic platforms. The 3.3 V TTL logic levels are compatible with standard microcontroller GPIO; for 5 V systems, a level shifter is required. Specific integration examples (firmware libraries, ROS drivers, sample code) should be requested from Benewake support.

Product inquiry

Talk to a product specialist

Tell us what you need and our team will get back to you.

Product inquiry

Inquiry sent

Your inquiry has been received. We will be in touch soon.