
TF350 UART / CAN User Manual
TF350 UART / CAN User Manual, including the parameters, figures and instructions in the original document.
TF3 50 - UA RT / CAN
Benewake (Beijing) Co., Ltd
PREFACE
Dear users: Thank you for choosing Benewake products. For the purpose of offering better operation experience to you, we hereby write this manual for an easier and simpler operation of our product, hoping to better solve the common problems you may meet.
This user manual contains the relevant information on product introduction, usage and maintenance of Long-range single-point LiDAR: TF350-UART / CAN, covers the product operation introduction and common problem solutions. Please read this manual carefully before using the product. Remember the precautions to avoid hazards, and please follow the described steps in the manual when using it.
If you have any problems in the process of usage, you are welcome to contact Benewake at any time for help.
Contact details Official website: en.benewake.com TEL:+86-10-57456983 Technical questions,please contact:support@benewake.com Consult sale information or request brochure,please contact:bw@benewake.com
Headquarters Address Benewake (Beijing) Co., Ltd.
3rd Floor, Haiguo Jiaye Sci-Tech Park, Haidian District, Beijing, China
Copyright Statement This User Manual is copyright © Benewake. Please do not modify, delete or translate the description of this manual contents without the official written permission from Benewake.
Disclaimer As our products are constantly improving and updating, the specifications of Long- range single-point LiDAR: TF350-UART / CAN. are subject to change. Please refer to the official website for latest version
1 OVERVIEW
The Reference Manual is a complement to the Operating Instructions for TF350. The Operating Instructions for TF350 describes how to set up and configure the interfaces.
The Reference Manual contains detailed information about the interfaces including syntax and available functionality. It focuses on TF350 specific topics and does not describe the basic technology behind each interface.
The details of the result output formatting and the contents and syntax of the command channels are shared by several interfaces. They are described in an appendix valid for all relevant interfaces.
1.1 Failure scenarios
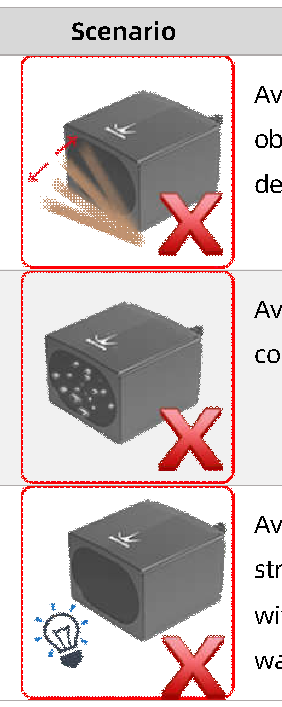
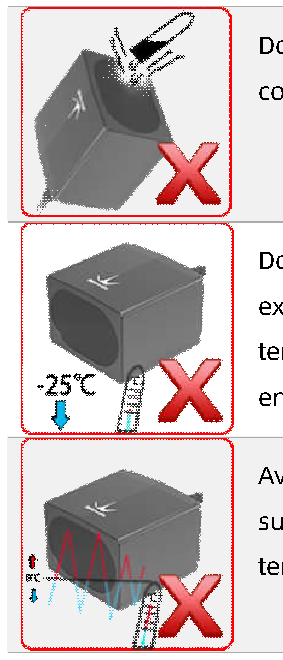
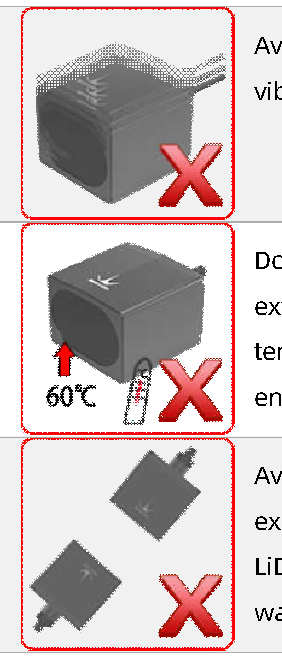
As a precision optical distance sensor, TF350 ’ s performance is greatly affected by environment. Certain scenarios will even damage TF350. Each of these failure scenarios have been tested in real field tests.
Table 1 Failure scenarios of TF350
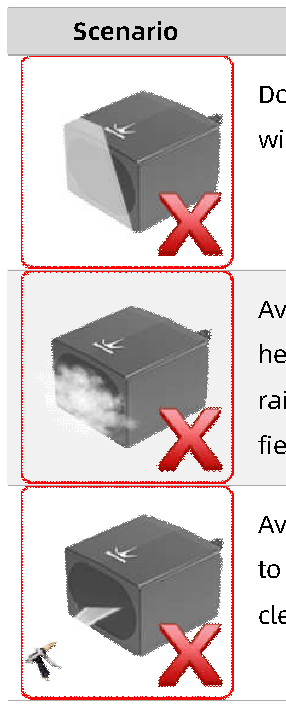
- Do not cover the laser window.
- Avoid moving objects in the detection field.
- Avoid the presence of heavy smoke, fog and rain in the detection field.
- Avoid condensation.
- Avoid direct exposure to high pressure cleaning.
- Avoid exposure to strong light source with same wavelength.
- Do not expose to corrosive liquids.
- Avoid extreme vibrations.
- Do not use in extremely low temperature environments.
- Do not use in extremely high temperature environments.
- Avoid exposure to sudden and extreme temperature changes.
- Avoid direct exposure to another LiDAR with same wavelength.
1.2 Symbols and document conventions
The following symbols and conventions are used in this document:
WARNING
Indicates a situation presenting possible danger, which may lead to death or serious injuries if not prevented.
CAUTION
Indicates a situation presenting possible danger, which may lead to moderate or minor injuries if not prevented.
NOTICE
Indicates a situation presenting possible danger, which may lead to property damage if not prevented.
NOTE
Indicates useful tips and recommendations.
2 PRODUCT DESCRIPTION
2.1 Appearance overview
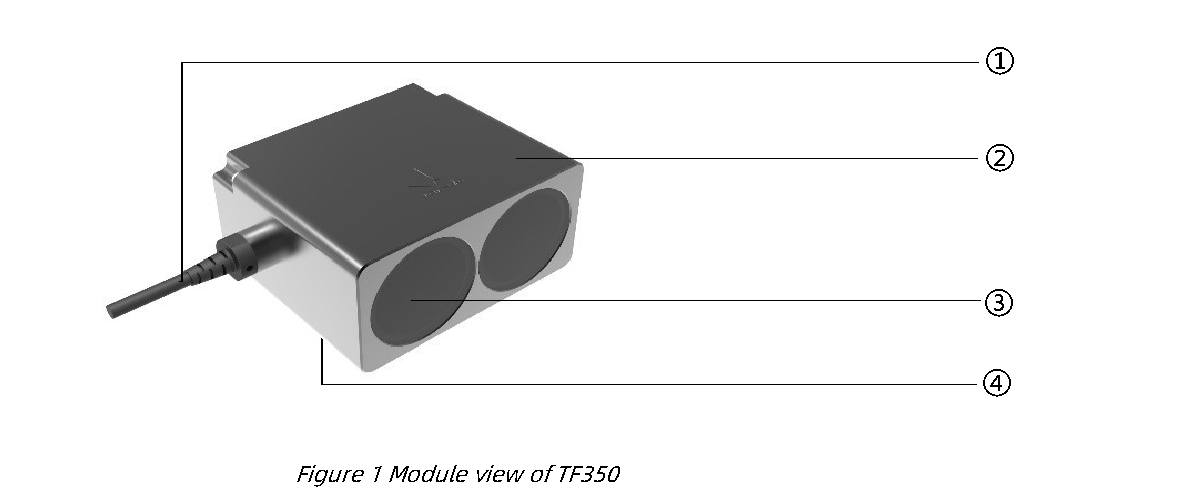
1 6 core cable (70cm), the connector is Molex SD-51021-007 1.25 W/B-7Pin also called MH1.25-7P-W/B.
2 Laser window (Receiving) 3 Laser window (Emitting) 4 3mm diameter hole (6mm deep) for mounting (6x)
2.2 Dimensional drawing
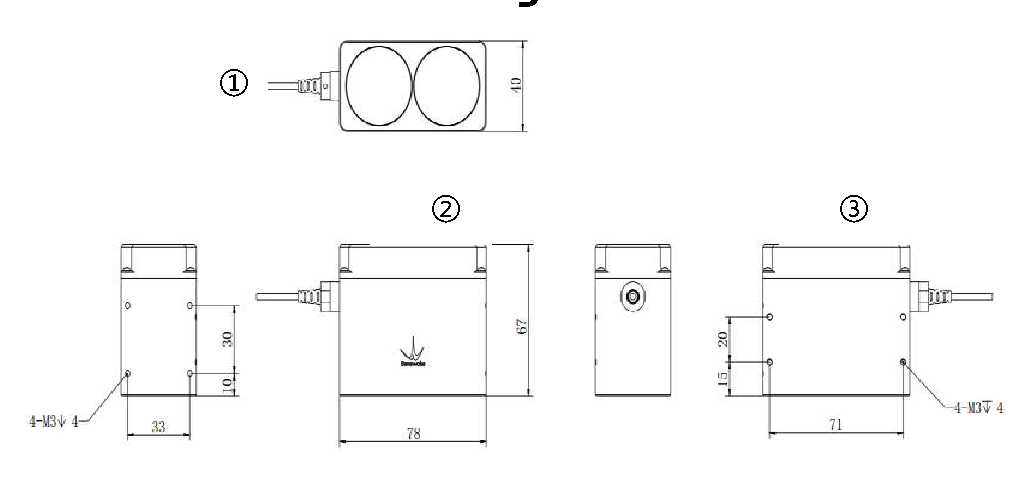
Figure 2 Dimensional drawing of TF350(①Front;②
2.3 Measuring principle
TF350 is a Pulse Time of Flight (PToF) sensor. TF350 emits a narrow pulse laser, which is
collimated by the transmitting lens, which enters the receiving system after being
reflected by the measured target and is focused on the APD detector by the receiving
lens. The time between the transmitted signal and the received signal is calculated
through the circuit amplification and filtering, and the distance between TF350 and the
measured target can be calculated through the speed of light.
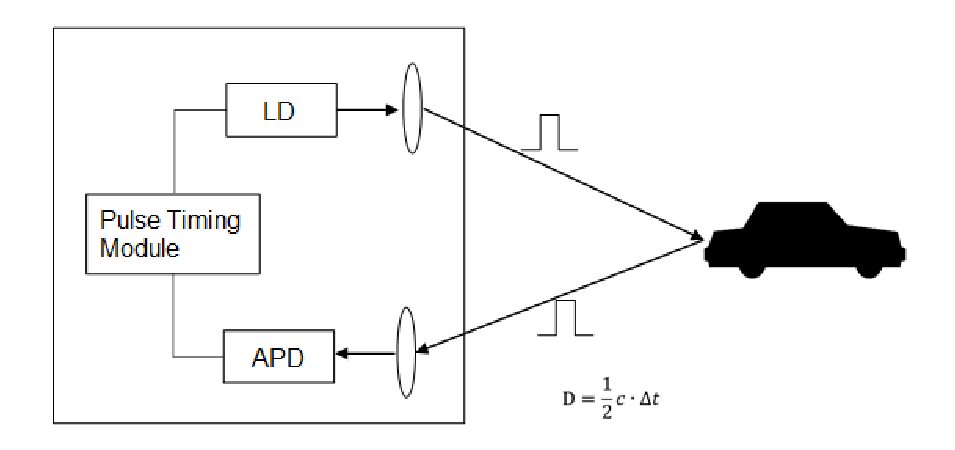
Figure 3 Pulsed time of flight(PToF)
2.4 Technical specification
Table 2 Technical specifications of TF350
| Parameters | Minimum | Typical | Maximum | |
|---|---|---|---|---|
| Performance | Range (@90% reflectivity, 0klux) | 0.2m | 350m | |
| Range (@10% reflectivity, 0klux) | 0.2m | 110m | ||
| Range (@90% reflectivity, 100klux) |
0.2m | 300m | ||
| Range (@10% reflectivity, 100klux) |
0.2m | 100m | ||
| Accuracy | ±10cm (<10m), 1% ≥10m) | |||
| Distance resolution | 1cm | |||
|---|---|---|---|---|
| Frame rate | 1Hz | 100Hz | 1000Hz | |
| Repeatability | 1σ: <3cm |
|||
| Light source | LD | |||
| Central wavelength | 905nm | |||
| Photobiological safety | Class1(EN60825) | |||
| FoV | 0.35° | |||
| Environment | Ambient light immunity | 100Klux | ||
| Operation temperature | -25℃ | 60℃ | ||
| Enclosure rating | IP67 | |||
| Connections | Supply voltage | 5V DC | 24V DC | |
| Average current | ≤150mA @ 5V, ≤80mA @ 12V, ≤ 50mA @ 24V |
|||
| Power consumption | ≤1W | |||
| Communication interface level | LVTTL (3.3V) |
|||
| Communication interface | RS-485 / RS-232 |
|||
| Others | Dimension | 78mm*67mm*40mm(L*W*H) | ||
| Housing | Aluminum alloy | |||
| Optical window | Infrared optical glass (HWB760) | |||
| Storage temperature | -40℃ | 85℃ | ||
| Weight | 222g ± 3g | |||
| Cable length | 70cm | |||
NOTICE
The basic technical specifications, like accuracy and repeatability, are measured with white background board (90% reflectivity) at 0klux condition.
NOTICE
Only the frame rate satisfying the following formula is supported.
Frame rate = a × 10b, a ∈ {1,2,3,4,5,6,7,8,9}, b ∈ {0,1,2,3} If a value which does not satisfy this formula is set, TF350 will set its frame
rate to 100Hz. The normal frame rate is under 1kHz, but the maximum frame rate can reach as much as 7kHz. Please contact us if you need higher frame rate.
2.5 FoV
The field-of-view, FoV, is the angle covered by the LiDAR sensor. The horizontal FoV of TF350 is about 0.35° and the vertical FoV of TF350 is approx. 0.1°.
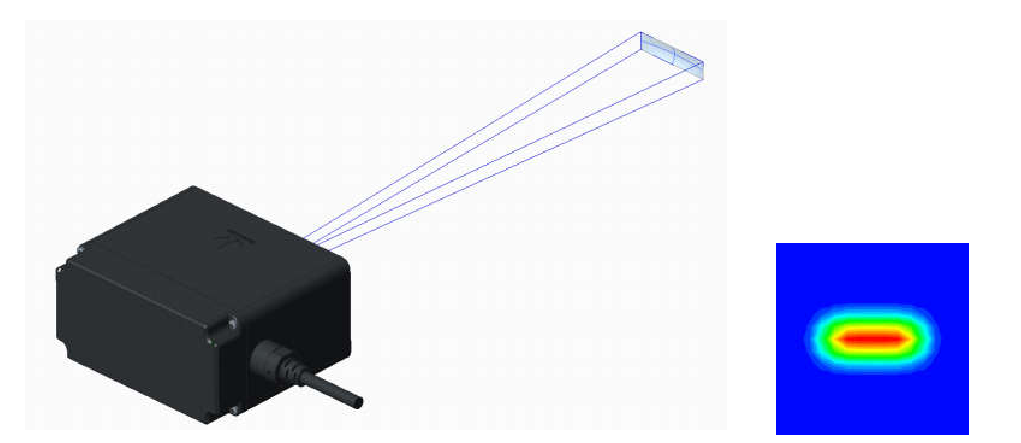
Figure 4 FoV of TF350.Horizontal divergence 0.35°,vertical divergence 0.1°
NOTICE
0.35° and 0.1° are theoretic values. Because the manufacturing error
and the installing error exist, there is divergence between each
TF350’s actual FoV and its theoretic values.
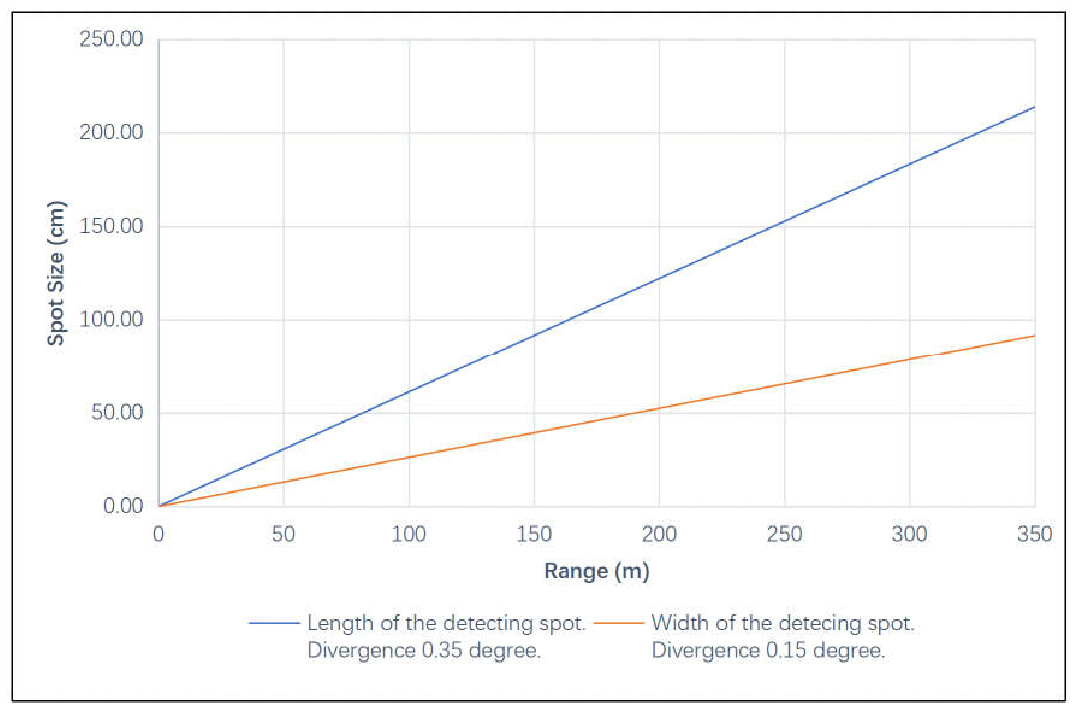
Figure 5 Spot size of TF350 at different ranges
3 ELECTRICAL INSTALLATION
3.1 Pin and wire color assignment
TF’s cable has six 26 AWG wires. The connector is Molex SD-51021-007 1.25 W/B-7Pin (MH1.25-7P-W/B).
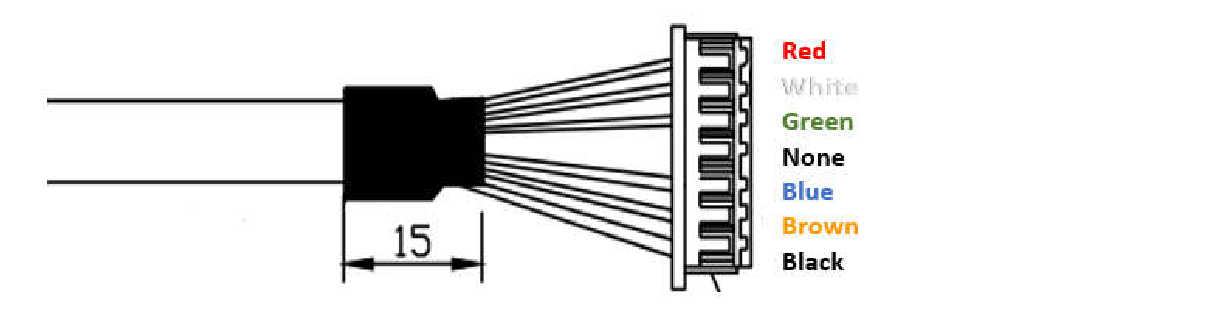
Figure 6 Male connector,MolexSD-51021-0071.25W/B-7Pin
Table 3 Pin assignment on 7-pin male connector
| Pin | Color | Signal | Function |
|---|---|---|---|
| 1 | Red | DC 5~24V | Supply Voltage |
| 2 | White | CAN_L | CAN-BUS Low |
| 3 | Green | CAN_H | CAN-BUS High |
| 4 | N/A | N/A | N/A |
| 5 | Blue | UART RxD | UART Receive |
| 6 | Brown | UART TxD | UART Transmit |
3.2 Wire cross-sections
CAUTION
If you use flexible connecting cables with stranded wire, then you must not use ferrules when connecting the wires to the terminals on TF350.
Wire all connections with copper cables!
Use the following wire cross-sections: • supply voltage at least 0.13 mm ² (approx. 26 AWG), if local power supply in the immediate vicinity.
• supply voltage at least 0.21 mm ² (approx. 24 AWG) at maximum length of 2m (6.562 ft), if the connection is made to an existing 24 V DC supply.
• switching outputs minimum 0.13 mm ² (approx. 26 AWG), maximum cable length 2m (6.562 ft) with 0.21 mm² (approx. 24AWG).
• data interface minimum 0.21mm² (approx. 24 AWG).
3.3 Wiring UART interface
A screened cable is required for the wiring of the UART interface.
- Pay attention to max. cable length as per section Wire cross-sections.
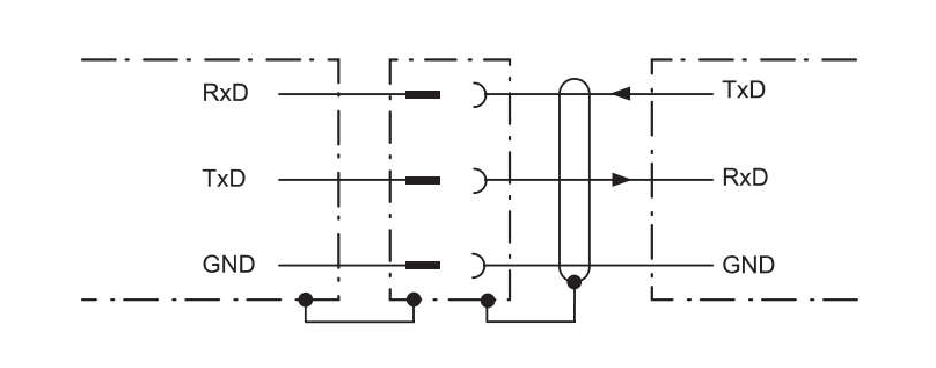
Figure 7 Wiring of the UART interface
NOTICE
To connect two devices for UART serial communication, the transmitter ’ s TXD should connect to the receiver ’ s RXD and the receiver ’ s TXD should connect to the transmitter’s RXD.
3.4 Wiring CAN interface
To wire the CAN interface a screened “twisted-pair” cable is required.
Pay attention to max. cable length as per section Wire cross-sections.
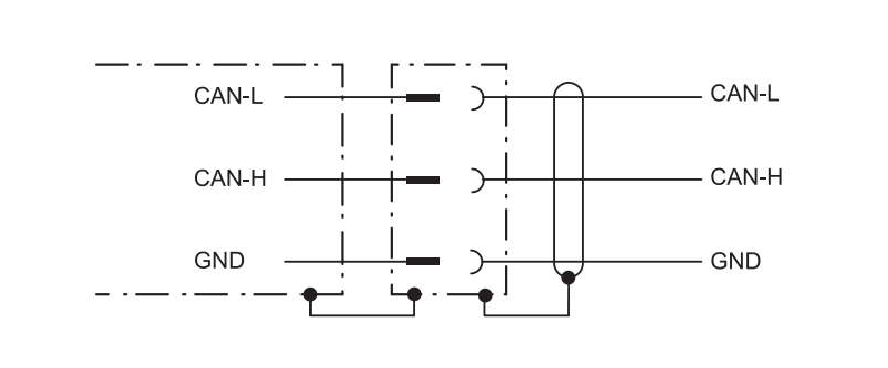
Figure 8 Wiring of the CAN interface
3.5 CAN bus
Unlike a traditional network such as USB or Ethernet, CAN does not send large blocks of data point-to-point from one node to another under the supervision of a central bus master.
Once CAN basics such as message format, message identifiers, and bit-wise arbitration - a major benefit of the CAN signaling scheme are explained, a CAN bus implementation is examined, typical waveforms presented, and transceiver features examined.
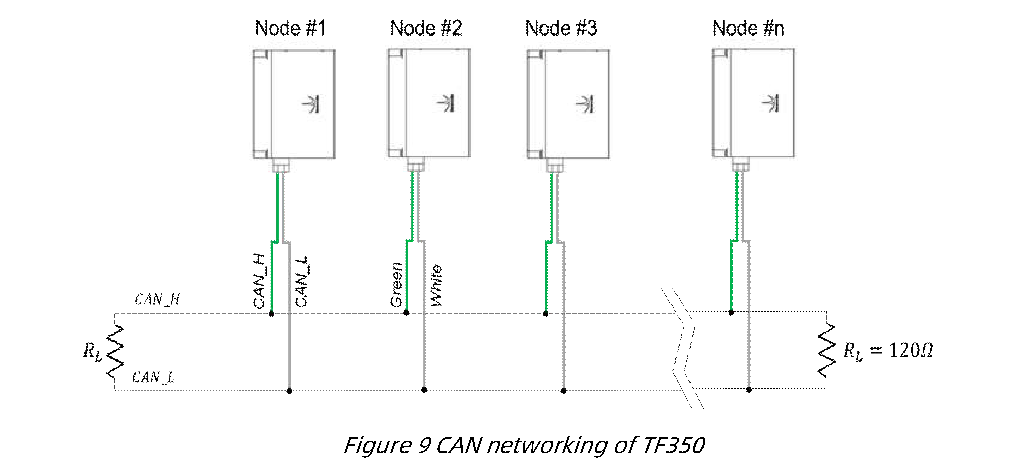
The High-Speed ISO 11898 Standard specifications are given for a maximum signaling rate of 1 Mbps with a bus length of 40 m with a maximum of 30 nodes. It also recommends a maximum unterminated stub length of 0.3 m. The cable is specified to be a shielded or unshielded twisted-pair with a 120-Ω characteristic impedance (Zo).
For CAN bus connection, there are two resistances need to be removed from TF350. See Figure 10 Resistances needed to be removed from board for CAN Bus for the location of Resistance #2 and #3.
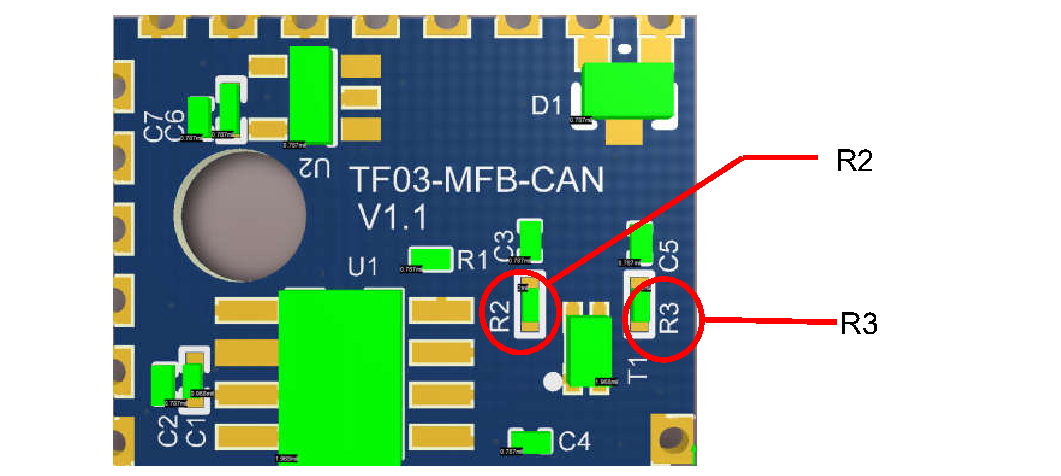
Figure 10 Resistances needed to be removed from board for CAN Bus
WARNING
Removing resistance R2 and R3 needs to disassemble TF350. To avoid irreversible damage to TF350, please contact our technical support engineers for detailed instructions.
4 PROTOCOLS
The standard version of TF350 supports two communication interfaces, UART and CAN.
The default interface is UART. These two interfaces cannot work simultaneously. The communication interface can be switched by certain command.
4.1 Communication protocol of UART
Table 4 Characteristics of UART
| Character | Value | Configurability |
|---|---|---|
| Baud rate | 115200 | Configurable |
| Data bit | 8 | Non-configurable |
| Stop bit | 1 | Non-configurable |
| Parity | None | Non-configurable |
NOTE
Baud rate of UART can be set to 9600, 14400, 19200, 38400, 56000, 57600, 115200, 128000, 230400, 256000, 460800, 512000, 750000, 921600, 1000000, 1500000 and 2000000. If other value were set, TF350 will automatically set it to 115200.
4.2 User protocol: UART
A standard data frame consists of 9 bytes of hexadecimal numbers, which contains distance and signal strength.
NOTE
Strength value is between 0 and 3500. Threshold of strength is 40, when strength is lower than 40, distance will output maximum value. When strength is between 40 and 1200, distance is more reliable. When detecting a high reflectivity object, signal strength will be over 1500.
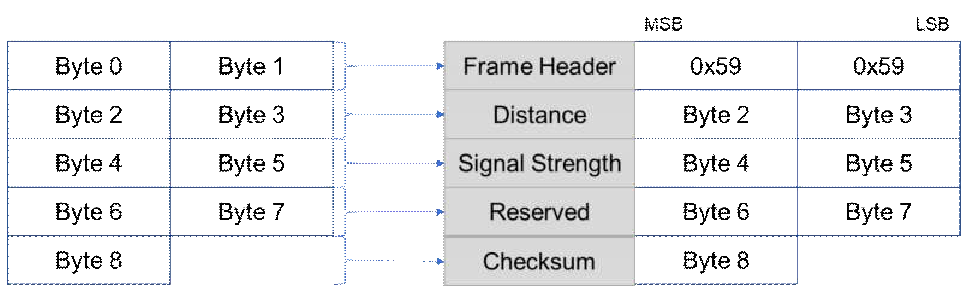
Figure 11 Data communication:User protocol frame format of UART Each data frame consists of 9 bytes hexadecimal data which contains the distance and signal strength.
NOTE
Strength value is between 0 and 3500. Threshold of strength is 40, when strength is lower than 40, distance will output maximum value. When strength is between 40 and 1200, distance is more reliable. When detecting a high reflectivity object, signal strength will be over 1500.
4.3 Communication protocol of CAN
The CAN interface supports data transmissions between 10Bit/s and 1Mbit/s. The maximum cable length is 2m (6.562ft).
Table 5 Characteristics of CAN
| Character | Value | Configurability |
|---|---|---|
| Baud rate | 1MBit/s | Configurable |
| Receiving ID | 0x3003 | Configurable |
| Transmitting ID | 0x03 | Configurable |
| Message frames | Standard Frame Extended Frame |
Configurable |
NOTE
Baud rate of CAN can be set to 20000, 33330, 40000, 50000, 66660, 80000, 83330, 100000, 125000, 200000, 250000, 400000, 500000, 666000, 800000 and 1000000. If other value were set, TF350 will automatically set it to 1000000.
4.4 User Protocol: CAN
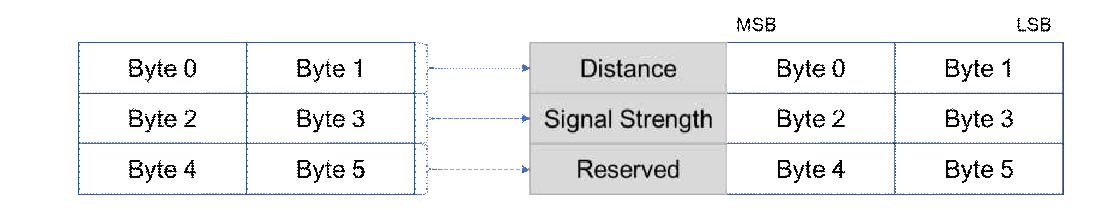
Figure 12 Data communication:User protocol frame format of CAN
5 CUSTOM CONFIGURATION
5.1 Protocol description
To meet the need of different customers, TF350 released several configuration parameters. These parameters, such as data format, frame rate, could be modified by certain command. All the parameters will be stored in flash after configured successfully and customers don’t need to configure again when restart.
Table 6 Description of TF350 command protocol
| Byte | Definition | Description |
|---|---|---|
| Byte 0 | Header | Fixed to 0x5A |
| Byte 1 | Len | The length of the entire instruction frame (unit: Byte) |
| Byte 2 | ID | Identifies the function of each instruction |
| Byte 3~Byte N-2 | Payload | Different meanings and lengths in different ID instruction frames |
| Byte N-1 | Check sum | The low 8 bits of the Len-1-byte data |
5.2 Common commands
Table 7 List of TF350’s common commands
| Description | Command | Response | Remark | Default setting |
|---|---|---|---|---|
| Obtain firmware version |
5A 04 01 5F | 5A 07 01 VA VB VC SU |
The version number VC.B.A |
/ |
| System reset | 5A 04 02 60 | 5A 05 02 00 61 | / | / |
| Modify frame rate |
5A 06 03 LL HH SU |
Same as command |
LL: lower 8 bits HH: higher 8 bits |
100Hz |
| Output control | On: 5A 05 07 01 67 Off: 5A 05 07 00 66 |
Same as command |
/ | Enabled |
| Enable command triggering mode |
5A 05 07 00 66 | Same as command |
/ | Disabled |
|---|---|---|---|---|
| Trigger measurement |
5A 04 04 62 | Data frame | Only works in command triggering mode |
/ |
| Change baud rate |
5A 08 06 H1 H2 H3 H4 SU |
Same as command |
See 5.3 Command editing |
115200 |
| Restore default settings |
5A 04 10 6E | 5A 05 10 00 6F | / | / |
| Save settings | 5A 04 11 6F | 5A 05 11 00 70 | / | / |
| Over range threshold setting |
5A 06 4F LL HH SU |
5A 05 4F 00 AE | Unit: cm LL: lower 8 bits HH: higher 8 bits |
35000 |
| Switch communication interface |
UART: 5A 05 45 01 A5 CAN: 5A 05 45 02 A6 |
5A 05 45 00 A4 | / | UART |
| Modify CAN arbitration ID |
5A 08 50 H1 H2 H3 H4 SU |
5A 05 50 00 AF | ID = (H4<<24) +(H3<<16) +(H2<< 8) +H1 |
0x03 |
| Modify CAN | 5A 08 51 H1 H2 H3 H4 SU |
5A 05 51 00 B0 | ID=(H4<<24) +(H3<<16) +(H2<< 8) +H1 |
0x3003 |
| Modify baud rate of CAN |
5A 08 52 H1 H2 H3 H4 SU |
5A 05 52 00 B1 | Baud rate=(H4<<24) +(H3<<16) +(H2<<8) +H1 |
1Mbits/s |
| Set frame type of CAN |
Standard frame: 5A 05 5D 00 BC Extension frame: 5A 05 5D 01 BD |
5A 05 5D 00 BC | / | Standard frame |
| Enable UAVCAN |
5A 05 77 MD SU | 5A 05 77 00 D6 | MD:filter switch 0x00:filter off 0x01:filter on |
/ |
| Offset setting | 5A 06 69 LL HH SU |
5A 05 69 00 C8 | Unit: cm LL: lower 8 bits HH: higher 8 bits |
0 |
|---|---|---|---|---|
| Low-power consumption mode |
On: 5A 05 83 01 E3 Off: 5A 05 83 00 E2 |
Same as command |
/ | Off |
WARNING
Do not send the command that is not in the list above.
NOTE
Offset configuration can be used for secondary calibration of distance, for example, when distance is 195cm and you want LiDAR outputs 200cm, you can set offset value to 5cm.
5.3 Command editing
This section describes the Command Channel of TF350 which is used to read and set TF350’s working parameters. The command channel is available via all the interfaces.
A standard TF350 command consists of frame header, command length, command ID, parameters, and checksum. Follow these steps to generate a command: • Choose the right command ID and confirm its length • Convert parameter from the decimal value to hexadecimal value • Fill the hexadecimal parameter into the command • Calculate the checksum and fill its low 8-bits into the command For example, changing the baud rate to 460800. Firstly, choose the ID of changing frame rate, which is 0x06. Secondly, change 460800 (decimal number) to hexadecimal number, which is 0x00 07 08 00. Thirdly, fill the parameter into the command, like 5A 08 06 00 08 07 00 SUM. Finally calculate the sum of the first 7bytes and take its low 8bits, we will have the complete command, 5A 08 06 00 08 07 00 77.
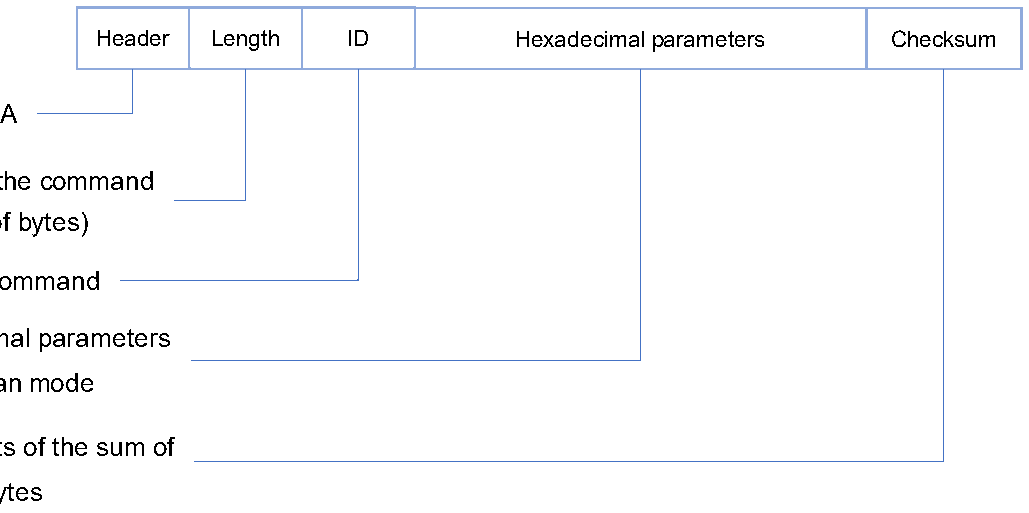
Fixed:0x5 Lengthoft (Numbero IDofthec Hexadecim Little-endi Lower8bit previousb
Figure 13 Command syntax of TF350
6 OPTIONAL ACCESSORIES
NOTE
The following accessories are not standard accessories, please contact our sales or technical personnel for more information.
6.1 Extension cord
For testing purposes, we prepared an extension Dupont cord. See Figure 14 Extension cord for test for detailed information.
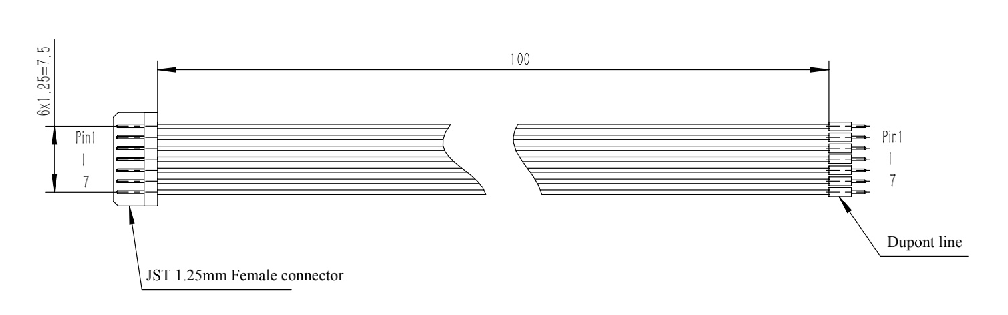
Figure 14 Extension cord for test
NOTE
This extension cord is free, but it’s not a standard accessory. Please contact us if needed.
7 QUICK START GUIDE
7.1 Connection and basic test
NOTE
The product package contains only TF350 and factory certificate. If you need USB converter, please contact our sales or technical support.
• Download the latest version BW_TFDS from http://en.benewake.com/support onto your PC or laptop.
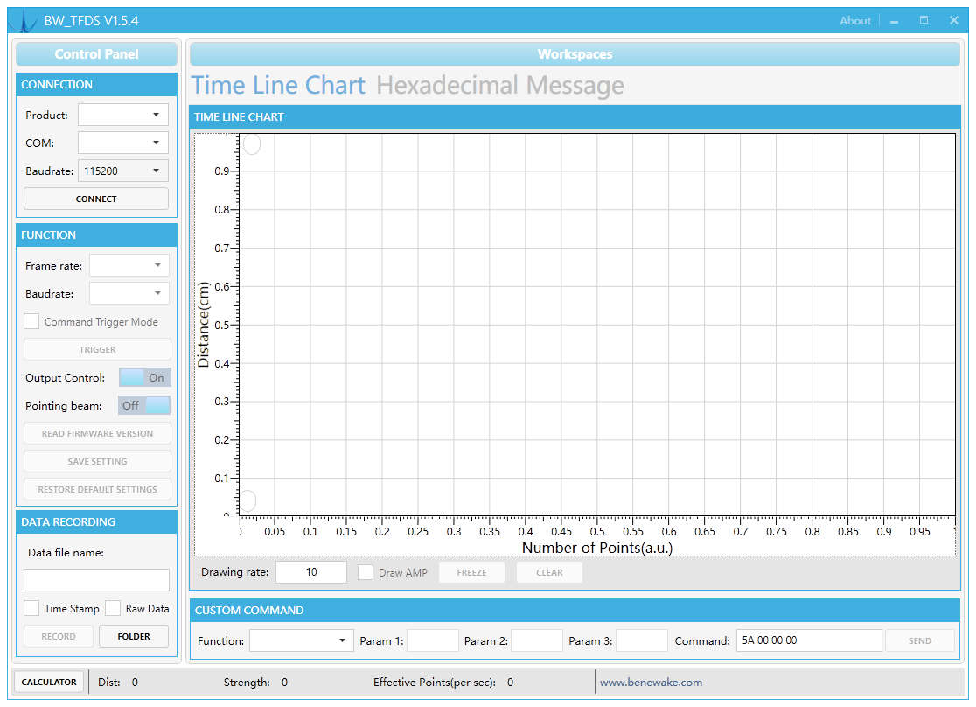
Figure 15 Benewake testing GUI for TF series • See Figure 15 Benewake testing GUI for TF series of the GUI.
• Connect TF350 to the PC or laptop with a paired USB converter cable as shown in Figure 16 TF350 connecting to PC. The UART version TF350 needs a UART-USB converter, and the CAN version TF350 needs a CAN-USB converter.
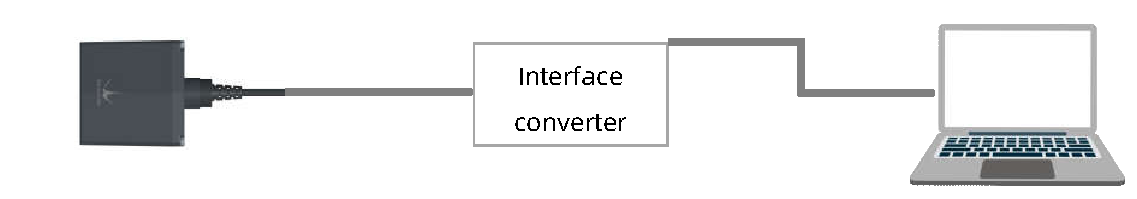
Figure 16 TF350 connecting to PC
• Run BW_TFDS.exe, choose the right baud rate and communication port, and click CONNECT to start the test.
7.2 Troubleshooting guide for initial test
In the default working mode, TF350 will automatically output data when connected to the PC following 7.1 Connection and basic test. If you cannot read data from GUI properly, follow these steps to locate and solve problems.
S1. Check if there is red light inside TF350 through its window.
▪ No. Check power supply. If the power supply is normal, please contact Benewake service.
▪ Yes. Proceed to S2.
S2. Check whether the USB converter is paired with TF350. For example, TF350-100 CAN needs a USB-CAN converter.
▪ No. Change a paired USB converter then try again.
▪ Yes. Proceed to S3.
S3. Check signal wiring. See Figure 7 Wiring of the UART interface and Figure 8 Wiring of the CAN interface for detailed wiring information.
▪ Incorrect. Fix wiring.
▪ Correct. Proceed to S4.
S4. Some USB converters can generate more than one COM port. Try to connect through different COM port.
▪ If all the COM ports don’t have data output, proceed to S5.
S5. Send the command of reading firmware version, 5A 04 01 5F, through every COM ports. Try to read response.
▪ If all the COM ports have no response, please contact Benewake service.
▪ If one of the COM ports has correct response, send the command of restore default, 5A 04 10 6E, through this COM port. After sending this command, if the TF350 still doesn ’ t work, please contact Benewake service.
7.3 Working mode
TF350 has three different working modes.
• Automatic output mode. This is the default working mode. The default frame rate of this mode is 10Hz.
• Command triggering mode. In this mode, TF350 will not output data automatically.
TF350 output measuring data only when it receives the triggering command.
• Low power consumption mode. In this mode, TF350 still output measuring data automatically. But the maximum frame rate has been restricted to 5Hz. Meanwhile its power consumption is reduced to 350mW.
NOTE
Only the UART interface supports low power consumption mode.
7.4 Influences of object surfaces on the
measurement
The signal received from a perfectly diffuse reflecting white surface corresponds to the definition of a remission of 100%. As a result of this definition, the remissions for surfaces that reflect the light bundled (mirrored surfaces, reflectors), are more than 100%.
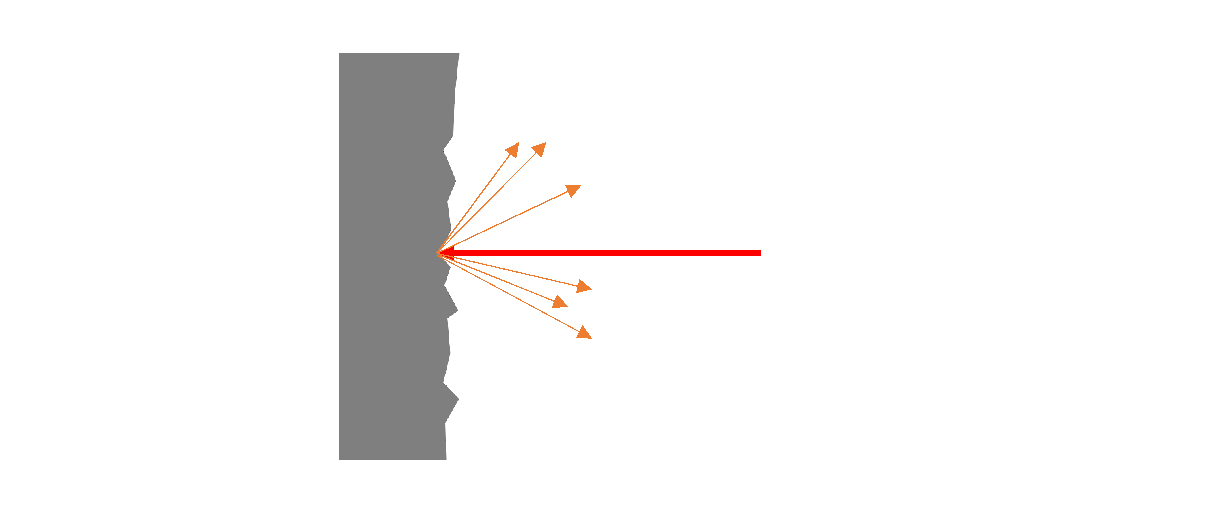
Figure 17 Reflection of the laser beam at the surface of an object The majority of surfaces reflect the laser beam diffusely in all directions.
The reflection of the laser beam will vary as a function of the surface structure and color. Light surfaces reflect the laser beam better than dark surfaces and can be detected by the TF350 over larger distances. Brilliant white plaster reflects approx.
100% of the incident light, black foam rubber approx. 2.4%. On very rough surfaces, part of the energy is lost due to shading. The detecting range of the TF350 will be
reduced as a result.
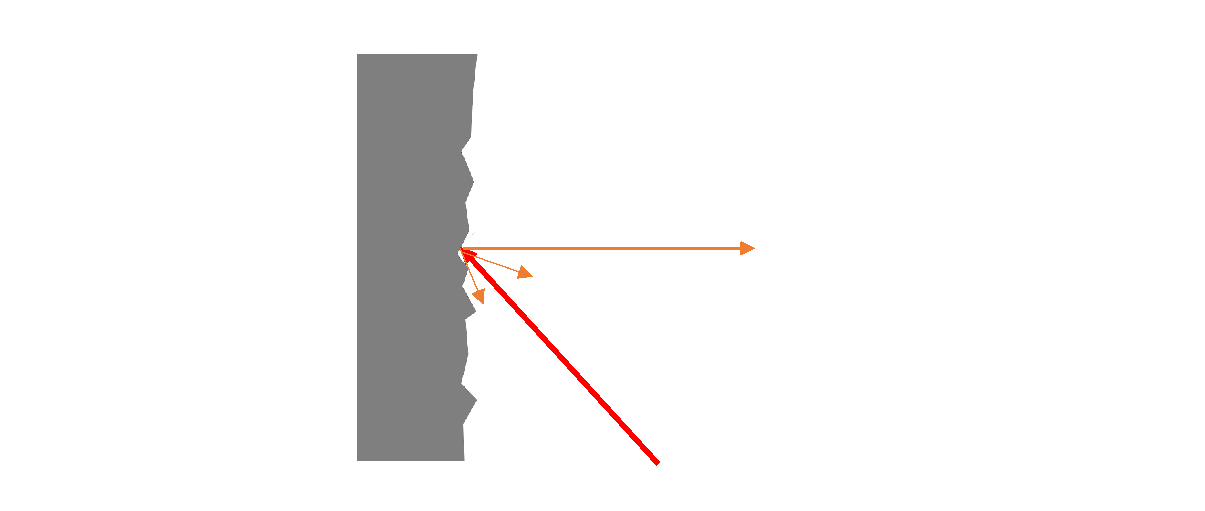
Figure 18 Reflection angle The reflection angle is the same as the angle of incidence. If the laser beam is incident perpendicularly on a surface, the energy is optimally reflected (Figure 18 Reflection angle). If the beam is incident at an angle, a corresponding energy and detecting range loss is incurred.
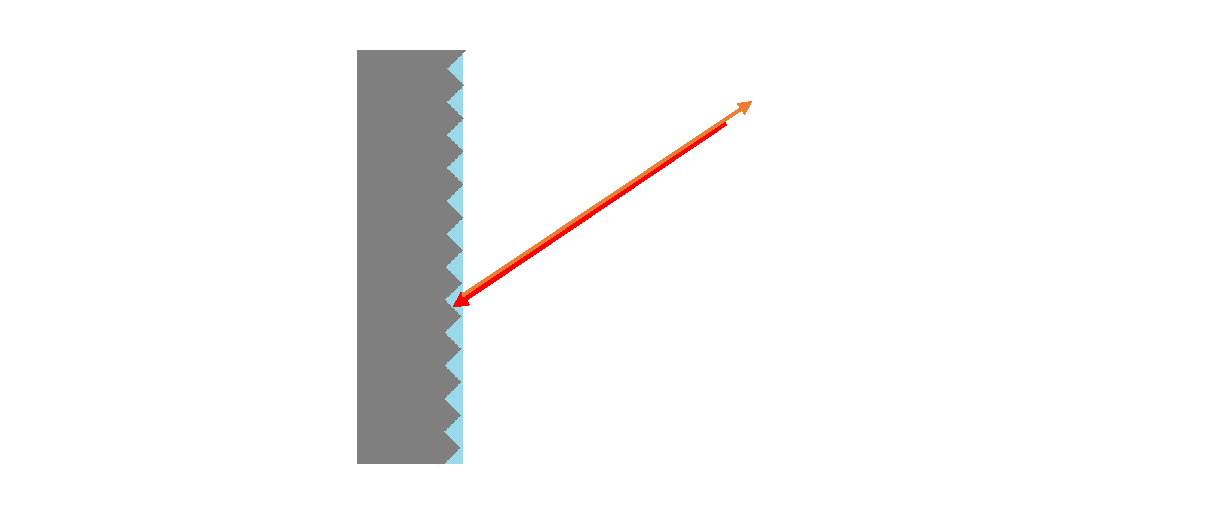
Figure 18 Degree of reflection If the reflected energy returned is over 100% (basis: Kodak standard) the incident beam is not reflected diffusely in all directions, but is reflected in a specific direction.
As a result, a large portion of the energy emitted can be received by the laser distance measurement device. Plastic reflectors (“cats’ eyes”), reflective tape and triple prisms have these properties.
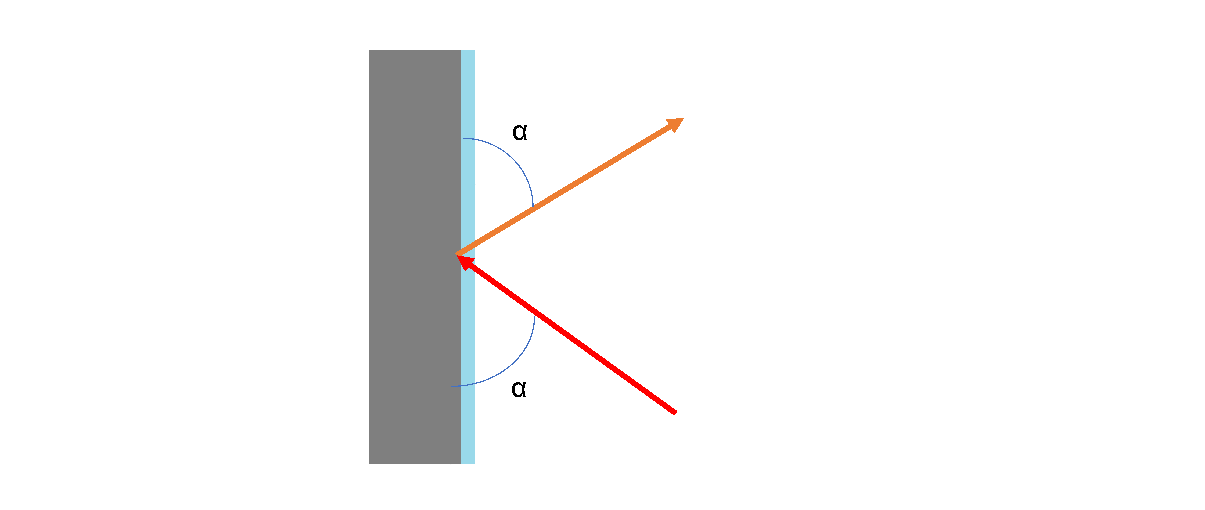
Figure 19 Mirror surfaces At mirror surfaces the laser beam is almost entirely deflected (Figure 19 Mirror surfaces). Instead of the surface of the mirror, it is possible that the object on which the deflected laser beam is incident may be detected.
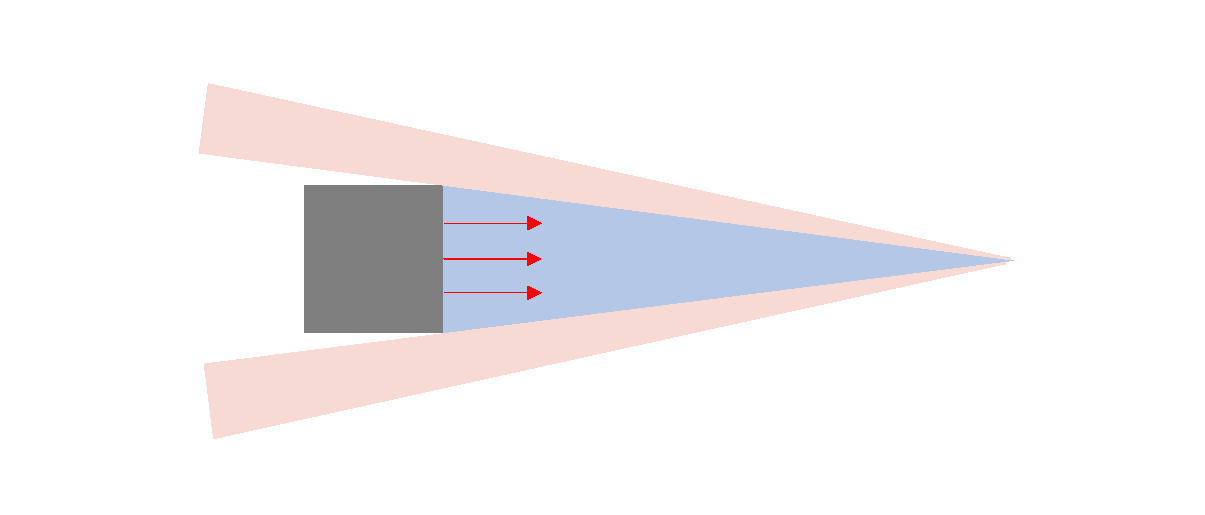
Figure 20 Object smaller than diameter of the laser beam Objects that are smaller than the diameter of the laser beam cannot reflect all the energy of the laser light (Figure 20 Object smaller than diameter of the laser beam).
The energy in the portion of the laser light that is not reflected is lost. This means that the detecting range is less than would be possible theoretically based on the surface of the object.
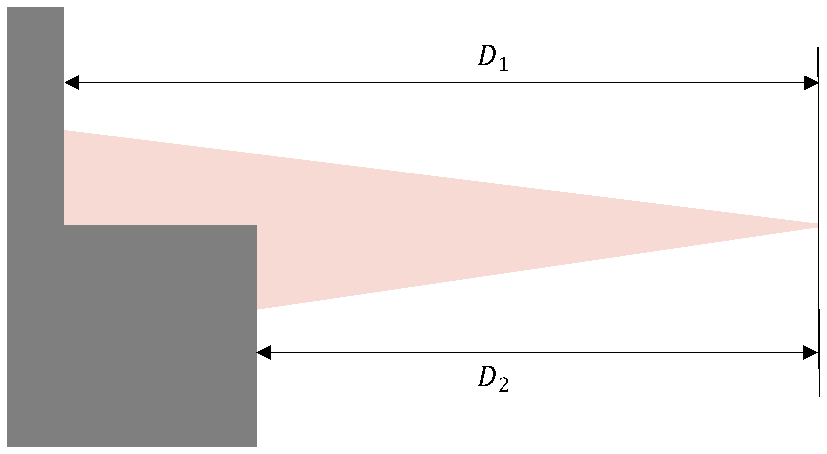
Dist = WightedAverage(D , D ) 1 2 Figure 21 Staircase object Staircase objects have two or more planes (Figure 21 Staircase object). The energy in the portion of the laser light that is reflected by different plane is different. TF350 will calculate a weighted averaging energy. The measured value will possible theoretically be the weighted average of distances from TF350 to different platform.
8 TROUBLESHOOTING
NOTICE
Claims under the warranty rendered void!
The housing screws of the TF350 are sealed. Claims under the warranty against Benewake will be rendered void if the seals are damaged or the device opened. The housing is only allowed to be opened by authorized service personnel.
This chapter describes how to identify and rectify errors and malfunctions during the
operation of TF350.
Table 9 Troubleshooting and rectification
| Failure | Possible cause | Solution |
|---|---|---|
| Measurement exceeds the allowed error. |
• Optical signal was blocked. |
• Remove the obstacle or adjust the detecting direction. |
| • The target is a low reflectivity object. |
• Paste a reflector on target object. |
|
| Measurements in the near range with no measurement target. |
• Protective film has not been removed. |
• Remove the protective film. |
| • Contaminated or scratched window. |
• Carefully clean optics using soft, fluff-free cloth. If the optics are scratched, contact Benewake service. |
|
| • Rain or fog | • Enable rain-fog filter | |
| TF350 is not transmitting a measured result. |
• Wiring fault in the data connection. |
• Check wiring. |
| • Wrong USB converter. | • Check USB converter. | |
| Data transmitted is garbage. |
• Baud rate mismatch. | • Check baud rate of the receiving device. Check TF350’s baud rate setting. |
| A certain target cannot be detected |
• The target is too small. | • Replace it with a larger target. Please refer to 2.5 |
| above. | ||
|---|---|---|
| • The target is a low reflectivity object. |
• Sticking a high reflection sticker on the surface of the measured object. |
Attachment 1: Reflectivity of Different
Materials
The reflectivity of different materials is listed below, ranging from low to high.
According to the test target and the corresponding reflectivity, we can measure whether the range of TF350 and other parameters meet the requirements.
| No. | Materials | Reflectivity |
|---|---|---|
| 1 | black foam rubber | 2.4% |
| 2 | black cloth | 3% |
| 3 | black rubber | 4% |
| 4 | Coal (varies from coal to coal) | 4~8% |
| 5 | Black car paint | 5% |
| 6 | Black paper | 10% |
| 7 | opaque black plastic | 14% |
| 8 | Clean rough board | 20% |
| 9 | newspapers | 55% |
| 10 | translucent plastic bottles | 62% |
| 11 | packing case cardboard | 68% |
| 12 | Clean pine | 70% |
| 13 | opaque white plastic | 87% |
| 14 | white card | 90% |
| 15 | Kodak standard whiteboard | 100% |
| 16 | Unpolished white metal surface | 130% |
| 17 | Shiny light metal surface | 150% |
| 18 | stainless steel | 200% |
| 19 | Reflective board, reflective adhesive tape | >300% |