
TF-Luna (underwater) User Manual
TF-Luna (underwater) User Manual, including the parameters, figures and instructions in the original document.
TF- Lun a
(Under wa ter )
User Man ual
Benewake (Beijing) Co., Ltd
PREFACE
Dear users: Thank you for choosing Benewake products. For the purpose of offering better operation experience to you, we hereby write this manual for an easier and simpler operation of our product, hoping to better solve the common problems you may meet.
This user manual contains the relevant information on product introduction, usage and maintenance of TF-Luna, covers the product operation introduction and common problem solutions. Please read this manual carefully before using the product. Remember the precautions to avoid hazards, and please follow the described steps in the manual when using it.
If you have any problems in the process of usage, you are welcome to contact Benewake at any time for help.
Contact Details Official website: en.benewake.com TEL:+86-10-5745 6983 Technical questions,please contact:support@benewake.com Consult sale information or request brochure,please contact:bw@benewake.com Headquarters Address Benewake (Beijing) Co., Ltd.
3rd Floor, Haiguo Jiaye Sci-Tech Park, Haidian District, Beijing, China Copyright Statement This User Manual is copyright © of Benewake. Please do not modify, delete or translate the description of this manual contents without the official written permission from Benewake.
Disclaimer As our products are constantly improving and updating, the specifications of TF-Luna are subject to change. Please refer to the official website for latest version.
1 REVISIONS
| Version No. |
History | Date |
|---|---|---|
| A00 | Original | 2024.7.24 |
2 CAUTIONS
2.1 About document
• This manual provides all essential information you may need during the usage of this product.
• Please read this manual carefully before using this product and make sure that you fully understand the contents of the manual.
2.2 About product
• The product can only be maintained and repaired by qualified professionals, and only original spare parts are permitted to use for performance and safety reasons.
• This product DOES NOT have polarity and over-voltage protection at all. Please wire and supply power according to the instructions.
• The working temperature of the product is from -10℃ to 60℃, please do not use it outside this temperature range to avoid risk and damage.
• The storage temperature of the product is from -20℃ to 75℃, please do not store it outside this temperature range to avoid risk and damage.
• For safety and performance, please DO NOT open the product casing or remove the IR-pass filter.
2.3 Common errors and other notes
• Detecting object with high reflectivity, such as mirrors, smooth floor tiles, and calm milk liquid.
• Blocking the product with any transparent objects, such as glasses.
• The product’s lens may be covered by dusts or dirt which may affect results, so please keep the lens clean.
• The exposed circuit board is electrostatic sensitive. Please do not touch the circuit board of the product barehanded. Please use ESD wrist strap or antistatic gloves to ground yourself if any operation is necessary; Otherwise, the product may be damaged by static electricity.
3 PRINCIPLE DESCRIPTION AND KEY
PARAMETERS
3.1 Ranging Principle
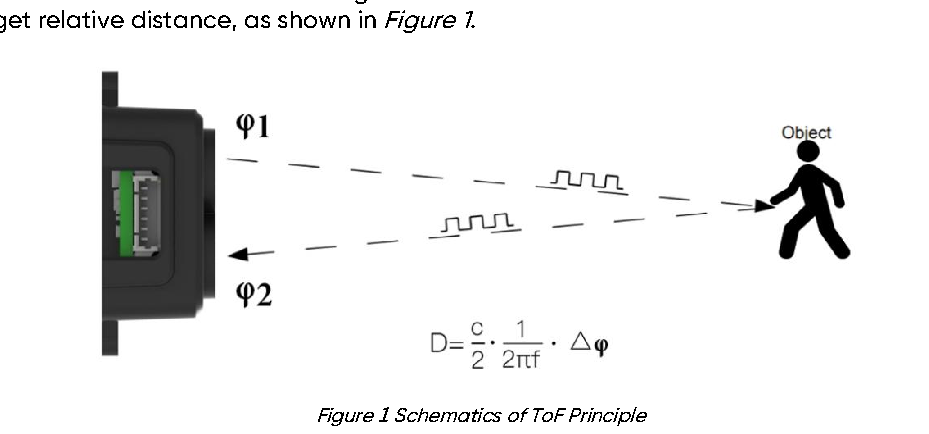
TF-Luna is using Time of Flight (ToF) principle to measure the distance and it periodically emits near infrared modulated waves. TF-Luna calculates the time by measuring the phase difference between the original wave and the reflection wave and uses that time
tog
3.2 Basic Characteristic Parameters
Table 1 Parameters specification of TF-Luna
| Description | Parameter value |
|---|---|
| Operating range | 5cm~55cm1 |
| Accuracy | <3 cm1 |
| Measurement unit | cm (Default) |
| Range resolution | 1cm |
| Frame rate | 1-250Hz2 |
| FoV | 2°3 |
1. The measurement distance is test with outdoors underwater, with the target object being common swimming pool wall tiles, under 25 ℃ conditions, 2. The Highest frame rate is 250Hz, the default frame rate is 100Hz. The customized update rate should be calculated by the formula: 500/n (n is more than 2), 3. This is a theoretical reference value.
4 APPEARANCE AND STRUCTURE
4.1 Dimensions
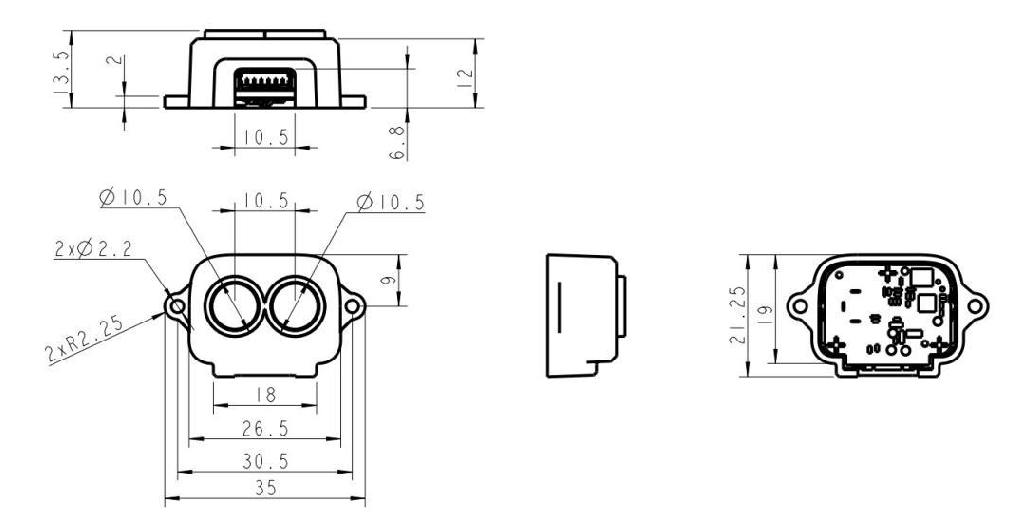
Figure3TF-Luna appearance and size drawing
5 ELECTRICAL CHARACTERISTICS
Table5 Major Electrical Parameters of TF-Luna
| Description | Value range |
|---|---|
| Power supply voltage | 3.7V-5.2V |
| Average current | ≤70mA |
| Peak current | 150mA |
| Power consumption | ≤350mW |
| Communication signal level |
LVTTL (3.3V) |
This product has no over-voltage nor polarity protection, so please make sure that the product is well connected, and the power supply voltage is inside the given range.
6 FUNCTIONAL DESCRIPTIONS AND
CONFIGURATION
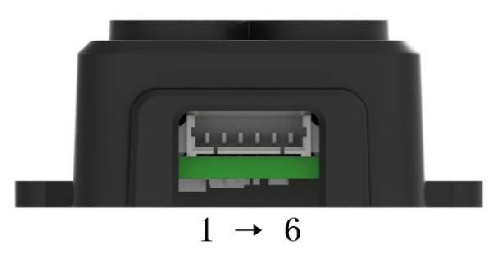
Figure4 TF-Luna’spinnumbers
6.1 Description about Line Sequence and
Connection
Table 6 The Function and Connection Description of Each Pin
| No. | Function | Description |
|---|---|---|
| 1 | +5V | Power supply |
| 2 | RXD/SDA | Receiving/Data |
| 3 | TXD/SCL | Transmitting/Clock |
| 4 | GND | Ground |
| 5 | Configuration Input | Ground: I²C mode Disconnected/3.3V: Serial port Communications mode |
| 6 | Multiplexing output | On/off mode: Output I²C mode: Data ready signal |
6.2 Serial Port Communication Protocol
Serial port communication starts when pin 5 is disconnected or connected to 3.3v. It will set TF-Luna receiving RXD on pin 2 and sending TXD on pin 3. The serial port communication protocol is defined as follows: 8 data bits, 1 stop bit with no parity check and default baud rate of 115200 bps.
Serial port communication protocol data byte format:
| byte | 0 | 1 | 2 | 3~Len-2 | Len-1 | |
|---|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Payload | Checksum |
Head: Fixed 0x5A.
Len: The length of bytes from the head byte to check-sum at the end, and it has to be in between 4 to 255.
ID: Indicates how to parse the payload data.
Payload: Payload data segment, optional.
Checksum: The lower 8 bytes of the sum from Head to Payload.
Please check Appendix II Serial communication protocol for more information.
Note: TF-Luna does not enable checksum check for sending data frames by default, that is, the Checksum at the end of the sending frame can be filled with any value. Thus, ANY value is acceptable on the Checksum byte, unless checking of those bytes is required.
Please check “Enable/disable checksum comparison ID_FRAME_CHECKSUM_EN=0x08” in Appendix II Serial communication protocol to enable the feature.
The instruction makes change immediately after sending, but the current setting is not saved and will be lost after reboot. User must use “Save current setting ID_SAVE_SETTINGS=0x11” to save the change. The full save-current-setting hexadecimal sequence is 5A 04 11 00 in this case.
6.3 I2C Communication
When pin 5 is connected to ground, TF-Luna enters I2C mode, then its pin 2 is used as SDA data and pin 3 is the SCL clock sending data. TF-Luna supports up to 400kps clock speed as slave machine and its default address is 0x10. For more information about I2C register table refer to Appendix III I2C register table.
Note: In this document, the address of I2C slave device is a 7-bit value with value range [0x08, 0x77] ([08, 119] in decimal). For the first byte after I2C releases a start signal, the 7-bit address should be shifted leftward for one bit (i.e. multiplied with 2), and then filled with the read-write sign on the lowest bit. For TF-Luna, the default address of slave device is 0x10, the address for write operations is 0x20, and the address for read operations is 0x21.
Write register timing: Start Slave Addr W Ack Register Addr Ack Data1 Ack … DataN Ack Stop Read register timing: Start Slave Addr W Ack Register Addr Ack Stop
Start Slave Addr R Ack Data1 Ack … DataN Nack Stop Note that in the read register sequence, the host can directly generate the second Start signal without generating the first Stop signal. The last Nack can also be an Ack signal.
In the continuous ranging mode, the host must monitor pin 6 for synchronous signal and initiate the read data operation in time. Otherwise, it may cause an error by reading and updating the data register at the same time. In multi-machine bus mode, use command
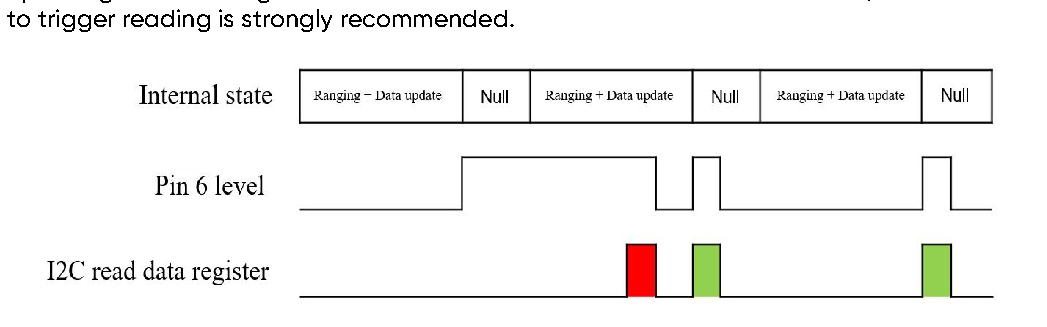
Figure 5 Timing of reading data register in I²Cmode Pin 6 is normal low level and it switches to high as soon as the data is updated. It switches to low level only if a read operation on any register is done. Therefore, I2C host must read the register when receive a high level on pin 6 in the continuous ranging mode. As the figure has shown above, the first result in red is unreliable and the rest two in green are accurate.
After a write operation on the I2C register, it takes TF-Luna some time to process. If users need to read the value from the register for validation purposes, we recommend waiting for 100ms after the write operation, prior to the next read operation.
6.4 Basic Data Output
TF-Luna normally provides these data below: • Distance (Dist): Default in centimeters.
• Signal strength (Amp): Distance value is unreliable when receiving signal is overexposed (Amp = 0xFFFF) or too low (Amp < 100). Normally, Amp value should not be above 30000. When Amp is above 32768, it indicates that TF-Luna has detected an ambient light overexposure, for instance, when it faces the sun in outside.
• Chip Temperature (Temp): Celsius degree = Temp/8 - 256℃ TF-Luna supports various serial format, please check Appendix I Serial port output format for more information, and the default setting is 9-bytes/centimeter. Format setting is in “Output format setting ID_OUTPUT_FORMAT=0x05” section.
6.5 Continuous Ranging Mode
TF-Luna will keep tracking the distance 500 times per second, but as the customized output frequency is lower, the output may take the average. For instance, if the output frequency is 100Hz as default, then the output values are the average (arithmetic mean) of 5 previous range data. Therefore, lower output frequency gives less time of the averaging process as well as less fluctuation of the output. The highest output frequency that TF-Luna supports is 250Hz (output_frequency ≤ 250Hz), and it must be 500/n Hz (where n is an integer that is in the range [2, 500]). Thus, all supported values of output frequency are: 250Hz, 166Hz, 125Hz, 100Hz, …, 2Hz, 1Hz. User can change the output frequency using “Output frequency ID_SAMPLE_FREQ=0x03”.
6.6 Trigger Mode
TF-Luna enters trigger mode if the output frequency is set to 0 with “Output frequency ID_SAMPLE_FREQ=0x03”. In this mode, TF-Luna stops measuring and outputting unless it is triggered by “Trigger mode ID_SAMPLE_TRIG=0x04” — in other words, TF-Luna measures and output once as soon as it receives the hexadecimal byte string 5A 04 04 00.
6.7 On/off Mode
On/off mode is designed from those users who only need to detect the existence of an object. TF-Luna can start this mode using “Enable/disable on-off mode ID_ON_OFF_MODE=0x3B” and then shows result through pin 6. Figure 6 below shows how
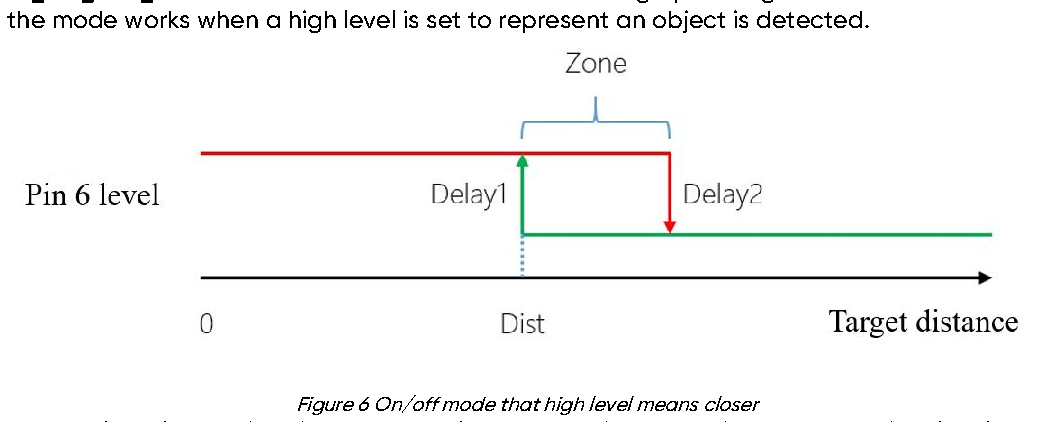
only if an object is detected farther than Dist + Zone, then Pin 6 outputs low-level. When zone is set to 0, pin 6 may output up and down cause by fluctuation of the measuring when the real distance happens to be the same as Dist. That is why a proper zone value is needed to help avoid this situation by having a hysteretic interval.
Delay is also supported to avoid inaccurate jumping output. Pin 6 changes its output depends on the Dist value condition and the time it lasts. Delay1(ms) and Delay2(ms) determine how long that approaching changes and leaving changes should wait after Dist value is already over the line.
Note: Since the Dist value is set to 0 under factory setting when no object is detected and Amp is too low, then pin 6 may have false output in the on/off mode. Please follow the instructions in 6.8 Amp to set the over-threshold value greater than Dist + Zone to avoid false output.
6.8 Amp Threshold
The distance calculation may get false result if the Amp value is too low, so TF-Luna set the Dist value to dummy_dist(Default 0) when Amp is lower than amp_threshold (Default
100). If a user needs to change the Amp threshold value, please follow instructions in “Amp threshold setting ID_AMP_THRESHOLD=0x22”. Note that the final Amp threshold in TF-Luna is 10 times the value you send to it.
6.9 Distance Limit
TF-Luna has a default maximum and minimum distance output: [min, max] = [0cm, 900cm].
User can change the output limits using “Distance limit setting ID_DIST_LIMIT=0x3A”.
Note: Any distance value lower than 20cm or greater than 800cm may be unreliable.
6.10 Power Saving Mode
The power consumption of TF-Luna is determined by two factors: the light source driving current and the light-emitting duty cycle.
TF-Luna adjusts the driving current of the light source adaptively to achieve the purpose of large dynamic range adapting to different distances and different reflectivity targets.
When the signal strength is too high, it will automatically switch to low gear current work.
On the contrary, when the signal strength is too low, it will automatically switch to high gear current work. The higher the current gear is, the greater the power consumption will be.
Refer to "6.5 Continuous Ranging ". In continuous ranging mode, TF-Luna always emits light with the highest duty cycle, which does not change with the output frequency.
Therefore, when TF-Luna is in continuous working mode and the current gear is at the highest gear, the power consumption is the largest. When the power is supplied with 5V, the power consumption is about 350mW.
The user can change TF-Luna's luminous duty cycle in two ways. The first is to use the command trigger mode. TF-Luna does not emit light when it does not receive a ranging command. At this time, the power consumption is about 42.5mW (5V power supply). The actual power consumption is determined by the frequency of the command trigger.
Another way is to enable the low power consumption mode provided by TF-Luna. The internal working mechanism of this mode is the same as the command trigger mode, except that the trigger signal is automatically generated internally by TF-Luna. The user can set the TF-Luna to enter the low-power mode through the "Enable/disable Power saving mode (ECO) ID_LOW_CONSUMPTION=0x35" instruction.
To ensure the internal working sequence of TF-Luna, the maximum output frequency of low power consumption mode is 10Hz. The following table lists the reference values of the average power consumption at different operating frequencies in the low power mode when the power supply is 5V. The actual power consumption may be affected by the ambient temperature or the supply voltage, and may differ from the reference value.
| Power saving frequency |
Avg current(mA) | Avg power (mW) |
|---|---|---|
| 1Hz | 8.85 | 44.25 |
| 2Hz | 9.2 | 46 |
| 3Hz | 9.55 | 47.75 |
| 4Hz | 9.9 | 49.5 |
| 5Hz | 10.25 | 51.25 |
| 6Hz | 10.6 | 53 |
| 7Hz | 10.95 | 54.75 |
| 8Hz | 11.3 | 56.5 |
| 9Hz | 11.65 | 58.25 |
| 10Hz | 12 | 60 |
6.11 Ultra-low Power Mode
In order to further reduce power consumption, TF-Luna offers an Ultra-low Power Mode. In this mode, MCU enters sleep mode, and the standby power consumption of TF-Luna is
about 1.5mW at this time. However, when MCU sleeps, it is not able to automatically awake as Low Power Mode is activated. Therefore, we need to change the voltage of Pin 2 to wake it up.
6.11.1 Ultra-low Power Mode with Serial Port
Communication
(1) Turn on Ultra-low Power Mode The command “Ultra-low Power Mode ID_ ULTRA_LOW_POWER_MODE=0x58” is used to turn on Ultra-low Power Mode. TF-Luna will stop serial port outputting data once the command is delivered. However, it will not enter the mode immediately. Users should send “Save current setting ID_SAVE_SETTINGS=0x11” to save current settings and then send “System software restore ID_SOFT_RESET=0x02” to reset system. Later on, TF-Luna will enter the Ultra-low Power Mode. Since the settings have been saved, TF-Luna will enter directly into this mode on next boot-up.
(2) Bring up Range-finding Users can wake up TF-Luna and make it perform range-finding once by sending a random byte to the serial port. TF-Luna will send back the range-finding result in a specific format, and then enter Ultra-low Power Mode once again. The following graph shows the case in which the baud rate is 115200 with 9-byte output format. The
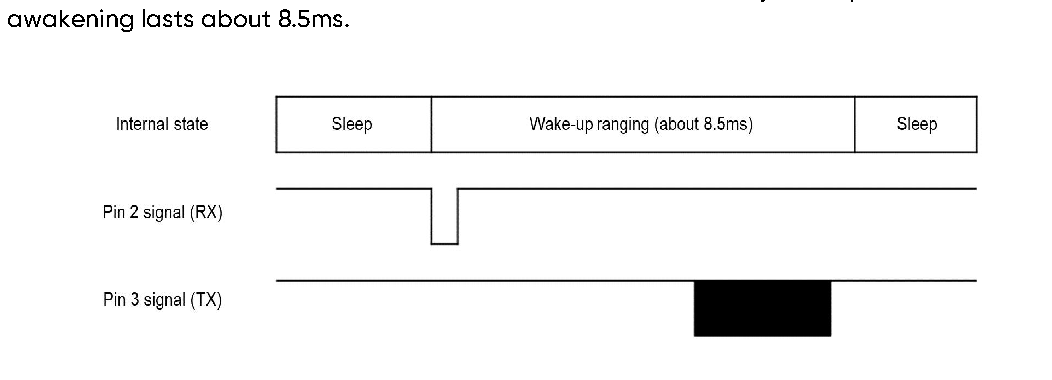
Figure 7 Time sequence of Ultra-low Power Mode with serial port communication (3) Turn off Ultra-low Power Mode Users cannot exit the Ultra-low Power Mode directly, because the serial port communication module is disabled. TF-Luna can only receive serial port commands during short intervals when it is awake. Therefore, users need to continuously send the command “Ultra-low Power Mode ID_ ULTRA_LOW_POWER_MODE=0x58” to disable the Ultra-low Power Mode untill TF-Luna responds. After that, users should send “Save current setting ID_SAVE_SETTINGS=0x11” command to save current settings.
(4) Estimation of Power Consumption TF-Luna consumes 1.5mW during sleep and on average 260mW during awakening. The awakening will last about 8.5ms. Based on the information, it consumes on average 3.7mW if we wake it up every second and on average 1.72mW if we wake it up every ten seconds.
6.11.2 Ultra-low Power Mode with I2C
communication
(1) Turn on Ultra-low Power Mode In order to turn on and save Ultra-low Power Mode, users need to write three consecutive bytes [0x01, 0x01, 0x02] to the address 0x1F.
(2) Bring up Range-finding Users can attempt reading any one of valid or invalid register addresses (which will not make us receive ACK from the slave device). In this way, TF-Luna will detect the change of voltage on Pin 2 and thus it will be awakened. TF-Luna will perform range-finding once
upon each awakening, and update the result on the register. It will not fall back to sleep
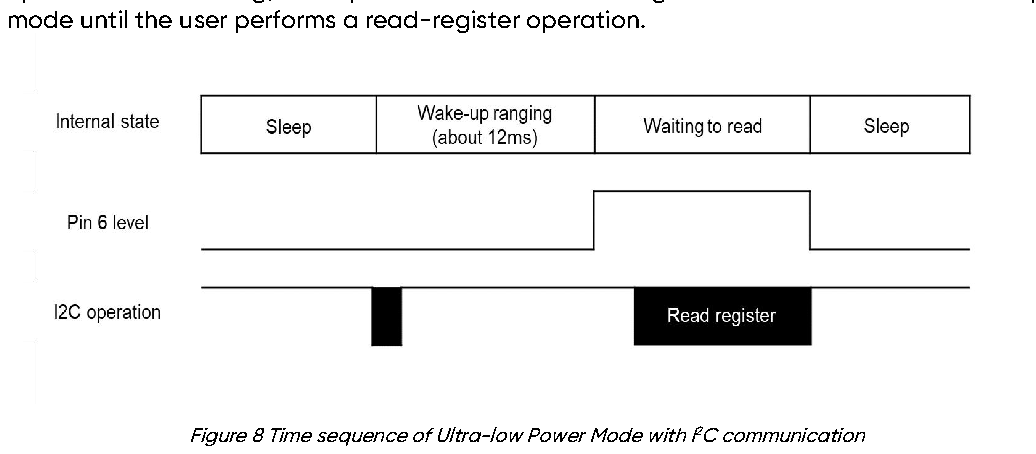
(3) Turn off Ultra-low Power Mode Reading the register will make TF-Luna enter sleep mode once again, therefore, in order to turn off the Ultra-low Power Mode, users need to write three consecutive bytes [0x00, 0x01, 0x02] to the address 0x1F after the awakening. It should be done no sooner than 6ms after the awakening).
(4) Estimation of Power Consumption TF-Luna consumes 1.5mW during sleep and on average 200mW during awakening.
Range-finding in an awakening period takes about 12ms, and awaiting users’ read-operation consumes about 42.2mW. Assuming it waits for 5ms, based on the information, it consumes on average 4.1mW if we wake it up every one second, and on average 1.76mW if we wake it up every ten seconds.
6.11.3 Caveats
Users should not send any setup command in the Ultra-low Power Mode, because MCU will be in sleep so that it may not respond to users’ command. In Ultra-low Power Mode, it is only allowed to bring up range-finding, or to turn off the mode. All other operations should be performed after the mode is turned off.
6.12 Single Frequency Mode
TF-Luna obtains distance measurement from phase shift of the sinusoidal modulated laser light. The model is subjected to the “periodic distance” problem. The periodic distance for TF-Luna is 15 meters, when working in Single Frequency Mode. However, when the distance is beyond 15 meters, the measured value starts from zero again. Assuming there is a highly reflective object at 16 meters; TF-Luna may mistake it as at 1 meter. In order to extend the periodic distance, TF-Luna sets the default work mode to Dual Frequency Mode. The periodic distance in such a mode is over 65 meters, far wider than the sensor’s measuring range. In this way, the “overshoot” problem is addressed.
However, in Dual Frequency Mode, the range-finding algorithm requires higher stability on sensor data. When the signal is weak (AMP lower than 100), the low data stability produces errors in the range algorithm, and thus yields anomalies in output range values.
The error can reach tens of meters. In some application scenarios, the target reflection rate is low so that AMPs lower than 100 are needed. In this case, users can set TF-Luna to Single Frequency Mode. In Single Frequency Mode, when AMP is lower than 100, the stability of range data is low. Even so, it is not allowed to have significant anomalies on data values. Meanwhile, users should make sure their application scenarios are not subjected to the overshoot problems.
6.13 Additional notes
Please check Appendix II Serial communication protocol for more options, such as version ID report, system software restore, baud rate configuration, etc.
7 QUICK TEST GUIDE
7.1 Required tools for testing
| TF-Luna | Data cable | TTL to USB convertor |
USB cable | PC | PC software |
7.2 Steps
1 Download and install the latest test software Please visit our official website (en.benewake.com) and download the test software of TF-Luna.
Note: Please turn off any anti-virus software before uncompressing the PC software.
Some anti-virus software may regard the ‘.exe’ file as virus. Also, released versions are only running on windows systems currently.
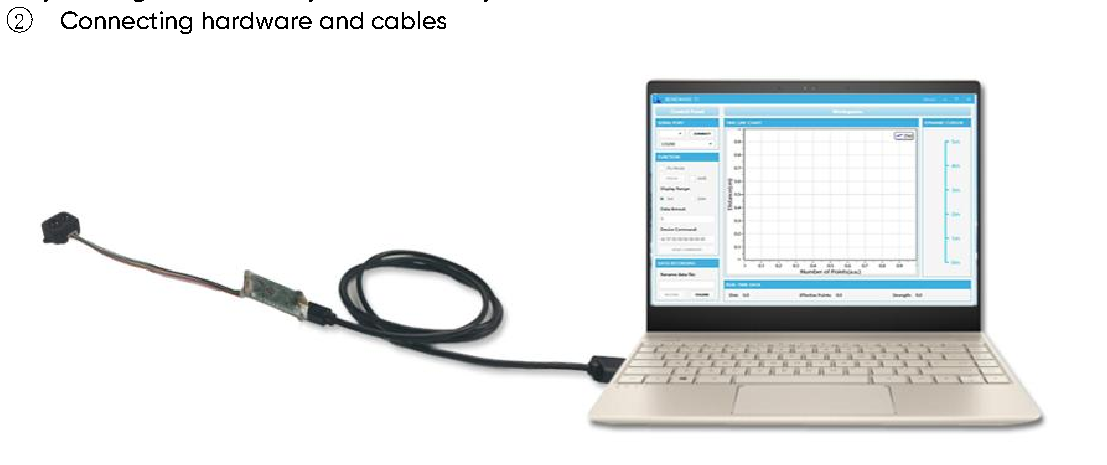
Figure 9 Schematic Diagram of Correct Connection Please connect TF-Luna, TTL-USB converter, and USB cable properly as shown in Figure 9.
Please check if there is any loose connection, and then plug the USB cable into your PC.
3 Open your test software and check data output Open the PC software and select “①TF-Luna” and select automatically recognized occupied serial port (in this case “② COM9”) as shown in Figure 10.
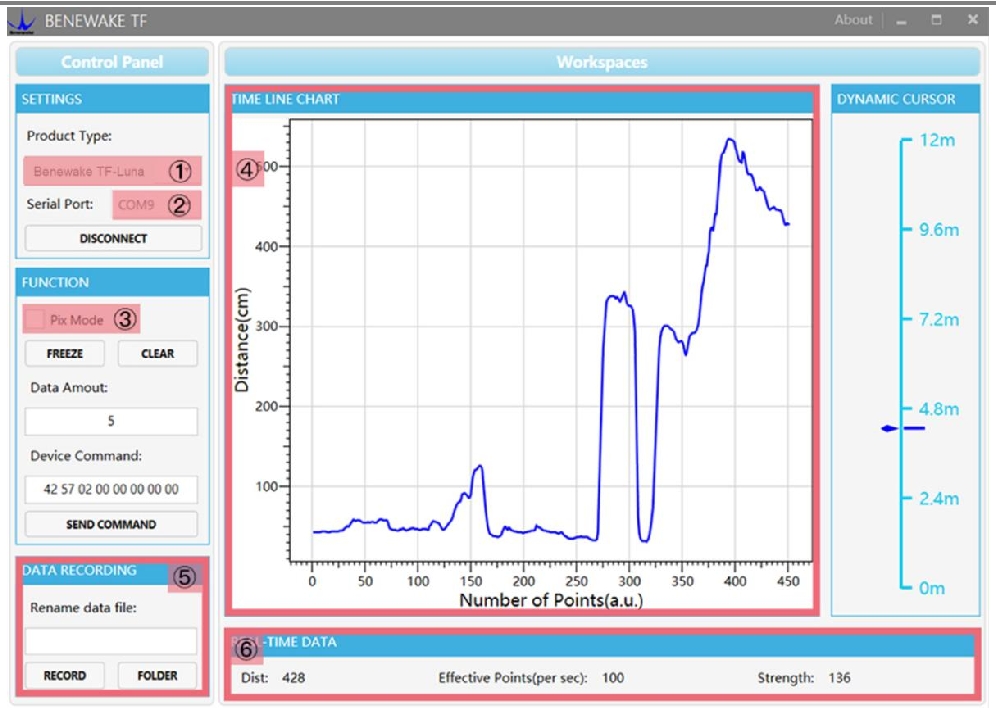
Figure 10 PC software Interface and Display Now click the “CONNECT” button, and a continuous images of the output data will be displayed in area “④ TIME LINE CHART” on the right if everything is connected successfully.
The real-time data of the Current measure distance (Dist), effective data points per second (Effective Points) and signal strength (Strength) will be displayed in area “⑥ REAL TIME DATA” below as well.
Notes: a) If nothing is displayed in area “④TIME LINE CHART”, please check the wire connection and sequence. A red LED indicator inside the transmitting lens at front will light up when TF-Luna is power-on.
b) Please select “③Pix Mode” before switching TF-Luna’s outputs to Pixhawk format to avoid abnormal data display in the “④TIME LINE CHART” area. Note that selecting Pix Mode will automatically set the unit of distance to meters.
c) Since TF-Luna does not pass unit information and the software always uses centimeters as distance unit, the distance unit displayed in the chart remains the same as centimeter even if TF-Luna output in millimeter. For instance, suppose the actual measurement is one meter and the distance value from TF-Luna is 1000 mm, then the value read by the PC software is 1000. Thus, the software will display 1000 with unit cm.
8 FIRMWARE UPGRADE
TF-Luna allows upgrading firmware remotely when current firmware no longer supports users’ new requirements. Please contact us for the additional remote upgrading software
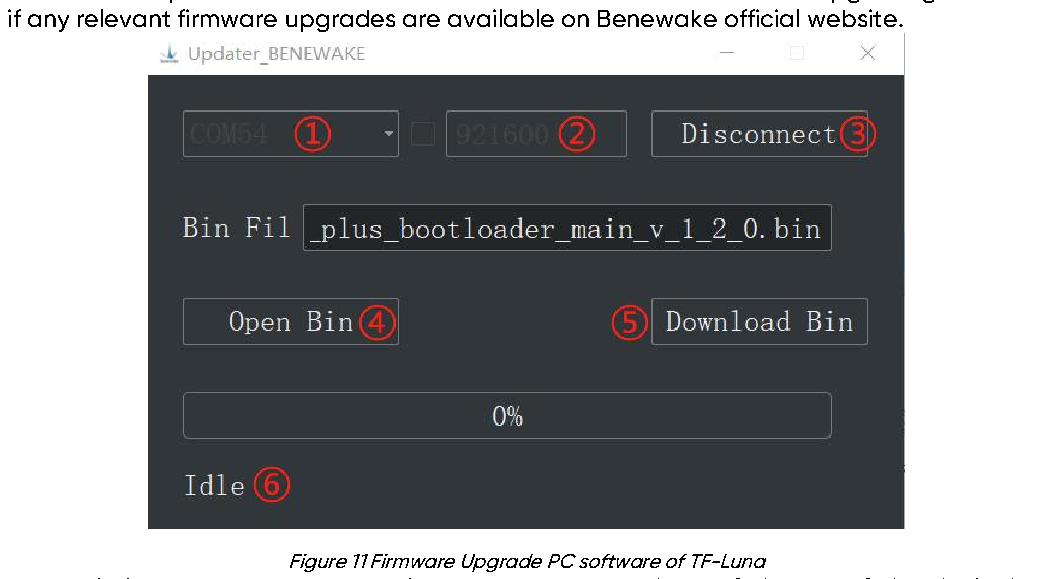
a TTL-USB convertor to connect TF-Luna with PC.
Open the Updater.exe after connecting TF-Luna to your PC, and then select the correct port and baud rate, “①COM8” and “② 115200” in this case. Click “④ Open Bin” to choose the updating firmware, then the file directory will be displayed in the textbox above.
Finally, click “⑤ Download Bin” to start upgrading and the upgrading information will show up in “⑥”.
Note: The full directory of the firmware files must use English letters only.
APPENDIX I SERIAL PORT OUTPUT
FORMAT
1. 9-byte/cm (Default)
This format is supported for any firmware after Ver. 0.0.5
| Byte | 0 | 1 | 2 | 3 | 4 | 5 | 6 | 7 | 8 |
|---|---|---|---|---|---|---|---|---|---|
| Description | 0x59 | 0x59 | Dist_L | Dist_H | Amp_L | Amp_H | Temp_L | Temp_H | Check_sum |
Dist: cm Amp: Signal strength indicator. Dist value is unreliable when Amp < 100 or Amp = 65535 (Overexposure) Temp: Celsius temperature = Temp / 8 - 256℃
2. PIX
This format is supported for any firmware after Ver. 0.0.5 “X.YZ\r\n” is a sample ASCII string and only keep two significant digits in meter where “X.YZ” is the result.
3. 9-byte/mm
This format is supported for any firmware after Ver. 0.0.5
| byte | 0 | 1 | 2 | 3 | 4 | 5 | 6 | 7 | 8 |
|---|---|---|---|---|---|---|---|---|---|
| Descriptio n |
0x59 | 0x59 | Dist_L | Dist_H | Amp_L | Amp_H | Temp_L | Temp_H | Check_sum |
Dist: mm Amp: Signal strength indicator. Dist value is unreliable when Amp < 100 or Amp = 65535 (Overexposure) Temp: Celsius temperature = Temp / 8 - 256℃
4. 32-byte with timestamp
This format is supported for any firmware after Ver. 0.0.5
| byte | 0 | 1 | 2 | 3 | 4 | 5 | 6-9 | 10 |
|---|---|---|---|---|---|---|---|---|
| Description | 0x59 | 0x59 | Dist_L | Dist_H | Amp_L | Amp_H | Timestamp | Check_sum |
Dist: cm Amp: Signal strength indicator. Dist value is unreliable when Amp < 100 or Amp = 65535 (Overexposure) Timestamp: Timestamp (ms) is in small-end format
5. ID-0 output
This format is supported for any firmware after Ver. 0.0.5
| byte | 0 | 1 | 2 | 3 | 4 | 5 | 6 | 7-10 | 11 |
|---|---|---|---|---|---|---|---|---|---|
| Description | 0x5A | Len | 0x00 | Dist_L | Dist_H | Amp_L | Amp_H | Timestamp | Check_sum |
Dist: cm Amp: Signal strength indicator. Dist value is unreliable when Amp < 100 or Amp = 65535 (Overexposure) Timestamp: Timestamp (ms) is in small-end format
6. 8-byte/cm
This format is supported for any firmware after Ver. 0.0.5
| byte | 0 | 1 | 2 | 3 | 4-7 |
|---|---|---|---|---|---|
| Description | Dist_L | Dist_H | Amp_L | Amp_H | Timestamp |
Dist: cm Amp: Signal strength indicator. Dist value is unreliable when Amp < 100 or Amp = 65535 (Overexposure) Timestamp: Timestamp (ms) is in small-end format
7. Output with Device ID
This format is supported for any firmware after Ver. 3.0.8
| byte | 0 | 1 | 2 | 3 | 4 | 5 | 6 | 7-10 | 11 | 12 |
|---|---|---|---|---|---|---|---|---|---|---|
| Descri ption |
0x5 A |
0x0 D |
0x0 0 |
Dist_ L |
Dist_ H |
Amp_L | Amp_ H |
Timestam p |
Dev_I d |
Check_sum |
Dist: cm Amp: Signal strength, if AMP is lower than 100, the range value is considered not reliable.
Overexposure value is 65535 Timestamp:Timestamp (ms) is in little-endian format Dev_Id: device ID, same as the address of I2C slave device
Appendix II Serial communication
protocol
1. Version information ID_GET_VERSION=0x01
This format is supported for any firmware after Ver. 0.0.5 Downward:
| byte | 0 | 1 | 2 | Len-1 |
|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Check_sum |
Upward:
| byte | 0 | 1 | 2 | 3~5 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | *Version | Check_sum |
*Version: For instance, if the third, fourth, and fifth bytes are 112, 50, 9, then the version is 9.50.112 Sample instruction: [5A 04 01 00]
2. System software restore ID_SOFT_RESET=0x02
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | Len-1 |
|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Check_sum |
Upward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | *Status | Check_sum |
*Status: 0 (success), otherwise (fail) Note: Any change without “save current setting” instruction will not be saved and will restore to original setting.
Sample instruction: [5A 04 02 00]
3. Output frequency ID_SAMPLE_FREQ=0x03
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3~4 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Freq | Check_sum |
| Default | 100 |
Freq: Working frequency if Freq > 0, and Trigger mode if Freq = 0.
Upward
| byte | 0 | 1 | 2 | 3~4 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Freq | Check_sum |
Freq: The current working frequency of the LiDAR Sample instruction: 10Hz [5A 06 03 0A 00 00] 250Hz [5A 06 03 FA 00 00]
4. Trigger mode ID_SAMPLE_TRIG=0x04
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | Len-1 |
|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Check_sum |
Upward Data frame Sample instruction: [5A 04 04 00]
5. Output format setting
ID_OUTPUT_FORMAT=0x05
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Format | Check_sum |
| Default | 0x01 |
Format: 0x01 = 9-byte/cm 0x02 = PIX 0x06 = 9-byte/mm 0x07 = 32-byte with timestamp 0x08 = ID-0 0x09 = 8-byte/cm 0x0A = Output with device ID Upward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Format | Check_sum |
Format: TF-Luna’s current output format setting Example: [5A 05 05 02 00] means PIX
6. Baud rate setting ID_BAUD_RATE=0x06
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3~6 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Baud rate | Check_sum |
| Default | 115200 |
Upward
| byte | 0 | 1 | 2 | 3~6 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Baud rate | Check_sum |
Baud rate: TF-Luna’s current baud rate.
Note: Only baud rate in [9600, 921600] are supported.
Example: 9600 [5A 08 06 80 25 00 00 00] 19200 [5A 08 06 00 4B 00 00 00] 38400 [5A 08 06 00 96 00 00 00] 57600 [5A 08 06 00 E1 00 00 00] 115200 [5A 08 06 00 C2 01 00 00] 230400 [5A 08 06 00 84 03 00 00] 460800 [5A 08 06 00 08 07 00 00] 921600 [5A 08 06 00 10 0E 00 00]
7. Enable/disable output ID_OUTPUT_EN=0x07
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Enable | Check_sum |
| Default | 1 |
Enable: 0 to disable, 1 to enable.
Upward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Enable | Check_sum |
Example: Enable output [5A 05 07 01 00] Disable output [5A 05 07 00 00]
8. Enable/disable checksum comparison
ID_FRAME_CHECKSUM_EN=0x08
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Enable | Check_sum |
| Default | 0 |
Enable: 0 to disable, 1 to enable.
Note: Even if the Downward data checksum comparison is disabled, the valid checksum is still included in the upward data frame Upward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Enable | Check_sum |
Example: Enable checksum comparison [5A 05 08 01 00] Disable checksum comparison [5A 05 08 00 67]
9. I2C slave machine address configuration
ID_I2C_SLAVE_ADDR=0x0B
This format is supported for any firmware after Ver. 1.0.0 Downward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | I2c_slave_addr | Check_sum |
| Default | 0x10 |
I2c_slave_addr: range [0x08, 0x77] Upward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | I2c_slave_addr | Check_sum |
Example: Change to 0x20 [5A 05 0B 20 00]
10. Restore default setting
ID_RESTORE_DEFAULT=0x10
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | Len-1 |
|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Check_sum |
Upward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Status | Check_sum |
Status: 0 for success, otherwise for errors Example: Restore default setting [5A 04 10 00]
11. Save current setting ID_SAVE_SETTINGS=0x11
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | Len-1 |
|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Check_sum |
Upward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Status | Check_sum |
Status: 0 for success, otherwise for errors Example: [5A 04 11 00]
12. Output product bar code
ID_READ_MANU_BIN=0x12
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | Len-1 |
|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Check_sum |
Upward
| byte | 0 | 1 | 2 | 3-16 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Bin | Check_sum |
Bin: 14 byte product bar code Example: Send [5A 04 12 00] Receive: U0900018010001, then the code is from the third byte to the sixteenth: 0x55 0x30 0x39 0x30 0x30 0x30 0x31 0x38 0x30 0x31 0x30 0x30 0x30 0x31
13. Get full-length version number
ID_GET_FULL_VERSION=0x14
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | Len-1 |
|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Check_sum |
Upward byte 0 1 2 3-10 1 12-19 2 21-22 2 24-25 2 27-28 Len-1
| 1 | 0 | 3 | 6 | ||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Descripti on |
Head (0x5A ) |
Le n |
I D |
Nam e |
‘.’ | Branc h |
‘.’ | Major versio n No. |
‘.’ | Minor versio n No. |
‘.’ | Revisio n version No. |
Check _sum |
Example: [5A 04 14 00]
14. Amp threshold setting
ID_AMP_THRESHOLD=0x22
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3 | 4-5 | Len-1 |
|---|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Amp_Threshold | Dummy_Dist | Check_sum |
| Default | 10 | 0 |
Amp_Threshold: When Amp < Amp_Threshold * 10, then output Dummy_Dist instead of the result of calculation Dummy_Dist: The output distance when Amp is too low.
Upward
| byte | 0 | 1 | 2 | 3 | 4-5 | Len-1 |
|---|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Amp_Threshold | Dummy_Dist | Check_sum |
Example: To output 500 cm when Amp < 300 [5A 07 22 1E F4 01 00]
15. Switch between Single Frequency and Dual
Frequency ID_ DEALIAS_EN =0x29
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Enable | Check_sum |
| Default | 1 |
Enable: 1(Dual Frequency Mode)0(Single Frequency Mode) Upward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Enable | Check_sum |
Example: Dual Frequency Mode [5A 05 29 01 00] Single Frequency Mode [5A 05 29 00 00]
16. Timestamp synchronization
ID_TIMESTAMP_SYNC =0x31
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3-6 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Std | Check_sum |
| Default | 0 |
Std: The current std timestamp specified Example: To set timestamp to 1000ms [5A 08 31 E8 03 00 00 00]
17. Enable/disable Power saving mode (ECO)
ID_LOW_CONSUMPTION=0x35
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3-4 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Sample_rate | Check_sum |
| Default | 0 |
Sample_rate: Work frequency if Sample_rate is positive (0 to disable power saving) Upward
| byte | 0 | 1 | 2 | 3-4 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Sample_rate | Check_sum |
Example: Enable power saving mode and measure at 10Hz frequency [5A 06 35 0A 00 00]
18. Filter Setup ID_FILTER_BIT_MAP=0x39
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Filter_bit_map | Check_sum |
| Default | 0x03 |
Filter_bit_map: Filter setup: 0 to disable, 1 to enable.
Bit0 – Kalman Filter Bit1 – Median Filter Upward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Filter_bit_map | Check_sum |
Example: Filter off [5A 05 39 00 00] Filter on [5A 05 39 03 00]
19. Distance limit setting ID_DIST_LIMIT=0x3A
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3-4 | 5-6 | 7 | Len-1 |
|---|---|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Dist_min | Dist_max | Silence | Check_sum |
| Default | 0 | 900 | 0 |
Dist_min: minimum distance output in centimeters.
Dist_max: maximum distance output in centimeters.
Silence: No output when the distance is out of range if silence = 1. Output limit when out of range if silence = 0 Upward
| byte | 0 | 1 | 2 | 3-4 | 5-6 | 7 | Len-1 |
|---|---|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Dist_min | Dist_max | Silence | Check_sum |
Example: Output limit when out of range with the minimum set to be 20cm and the maximum set to be 500cm [5A 09 3A 14 00 F4 01 00 00]
20. Enable/disable on-off mode
ID_ON_OFF_MODE=0x3B
This format is supported for any firmware after Ver. 1.0.0 Downward
| byte | 0 | 1 | 2 | 3 | 4-5 | 6-7 | 8-9 | 10-11 | Len-1 |
|---|---|---|---|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Mode | Dist | Zone | Delay1 | Delay2 | Check_sum |
| Default | 0 | 0 | 0 | 0 | 0 |
Mode: 0 (Normal output), 1 (On-off mode with high level output when closer) , 2 (On-off mode with low level output when closer) Dist: critical dist value (the closer one) in centimeters.
Zone: Zone size in centimeters Delay1: Delay time 1 in millisecond. Pin 6 switch level only if the distance detected is less than Dist and the situation last for Delay1 long.
Delay2: Delay time 2 in millisecond. Pin 6 switch level only if the distance detected is more than Dist + Zone and the situation last for Delay2 long.
Example: Enable on-off mode with high level output when closer, and set Dist = 200cm, Zone=10cm, Delay1 = Delay2 = 1000ms: [5A 0D 3B 01 CB 00 0A 00 E8 03 E8 03 00]
21. Read config by id
ID_GET_CONFIG_PARA=0x3F
This format is supported for any firmware after Ver. 0.0.5 Downward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Id | Check_sum |
Id: The same as we mentioned above.
Upward: The same format of relevant Id.
Example: Read output frequency [5A 05 3F 03 00]
22. Ultra-low Power Mode ID_
ULTRA_LOW_POWER_MODE=0x58
This format is supported for any firmware after Ver. 3.0.7 Downward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Enable | Check_sum |
Enable:0 to disable, 1 to enable.
Upward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Enable | Check_sum |
Example: Turn on Ultra-low Power Mode [5A 05 58 01 00] Turn off Ultra-low Power Mode [5A 05 58 00 00]. Since there is a time period in an Ultra-low Power Mode awakening phase, the turn-off command should be sent multiple times, e.g. [5A 05 58 00 00 5A 05 58 00 00 5A 05 58 00 00 5A 05 58 00 00 5A 05 58 00 00]
23. Frequency Calibration
ID_FREQ_CNT_CALIB=0x59
This format is supported for any firmware after Ver. 3.0.7
Downward
| byte | 0 | 1 | 2 | 3 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Cmd | Check_sum |
Cmd : 1 (Execute frequency calibration, which takes about two seconds), 2 (Read frequency calibration parameters) Upward
| byte | 0 | 1 | 2 | 3-4 | Len-1 |
|---|---|---|---|---|---|
| Description | Head(0x5A) | Len | ID | Calib_freq_cnt | Check_sum |
Calib_freq_cnt : For frequency calibration parameters, a non-zero value indicates the completion of calibration Example: Execute frequency calibration [5A 05 59 01 00] Read frequency calibration parameters [5A 05 59 02 00]
Appendix III I2C REGISTER TABLE
| Address | R/W | Name | Initial Value |
Description |
|---|---|---|---|---|
| 0x00 | R | DIST_LOW | -- | cm |
| 0x01 | R | DIST_HIGH | -- | |
| 0x02 | R | AMP_LOW | -- | |
| 0x03 | R | AMP_HIGH | -- | |
| 0x04 | R | TEMP_LOW | -- | Unit: 0.01 Celsius |
| 0x05 | R | TEMP_HIGH | -- | |
| 0x06 | R | TICK_LOW | -- | Timestamp |
| 0x07 | R | TICK_HIGH | -- | |
| 0x08 | R | ERROR_LOW | -- | |
| 0x09 | R | ERROR_HIGH | -- | |
| 0x0A | R | VERSION_REVISION | -- | |
| 0x0B | R | VERSION_MINOR | -- | |
| 0x0C | R | VERSION_MAJOR | -- | |
| 0x0D-0x0F | -- | Hold | ||
| 0x10-0x1D | R | SN | -- | Production code in 14 bytes ASCI code (0x10 is the first byte) |
| 0x1E | -- | Hold | ||
| 0x1F | W | ULTRA_LOW_POWER | -- | 0x00: Normal 0x01: Ultra-low power mode |
| 0x20 | W | SAVE | -- | Write 0x01 to save current setting |
| 0x21 | W | SHUTDOWN/REBOOT | -- | Write 0x02 to reboot |
| 0x22 | W/R | SLAVE_ADDR | 0x10 | Range: [0x08, 0x77] |
| 0x23 | W/R | MODE | 0x00 | 0x00: Continuous ranging mode 0x01: Trigger mode |
| 0x24 | W | TRIG_ONE_SHOT | -- | 0x01: Trigger once (only on trigger mode) |
| 0x25 | W/R | ENABLE | 0x01 | 0x00: Turn off LiDAR 0x01: Turn on LiDAR |
| 0x26 | W/R | FPS_LOW | 0x64 | |
| 0x27 | W/R | FPS_HIGH | 0x00 | |
| 0x28 | W/R | LOW_POWER | 0x00 | 0x00: Normal 0x01: Power saving mode |
| 0x29 | W | RESTORE_FACTORY_DEFAULTS | -- | Write 0x01 to restore factory default settings |
| 0x2A | W/R | AMP_THR_LOW | 0x64 | Amp threshold value |
| 0x2B | W/R | AMP_THR_HIGH | 0x00 | |
| 0x2C | W/R | DUMMY_DIST_LOW | 0x00 | Dummy dist value |
| 0x2D | W/R | DUMMY_DIST_HIGH | 0x00 | |
| 0x2E | W/R | MIN_DIST_LOW | 0x00 | Minimum dist in mm, but not working on DUMMY_DIST |
| 0x2F | W/R | MIN_DIST_HIGH | 0x00 |
| 0x30 | W/R | MAX_DIST_LOW | 0x20 | Maximum dist in mm, but not working on DUMMY_DIST |
|---|---|---|---|---|
| 0x31 | W/R | MAX_DIST_HIGH | 0x03 | |
| 0x32-0x3B | -- | Hold | ||
| 0x3C-0x3F | R | SIGNATURE | -- | ‘L’ ’U’ ‘N’ ‘A’ |