Configuring TFmini-Plus on Ardupilot using PixHawk1 (IIC)
Configuring TFmini-Plus on Ardupilot using PixHawk1 (IIC), including the parameters, figures and instructions in the original document.
on Ardupilot Flight Stack using PixHawk1
Flight Controller
for the purpose of Altitude Holding or Obstacle Avoidance (both will be explained in this document).
At the time of writing this document the controller used was PixHawk1 flashed with ArduCopter V4.0.4.
But this document can be used with other flight controllers running with different ArduCopter firmware versions with slight modification in parameter names and choosing the right port on flight controller.
1. TFmini-Plus Settings:
Note: If there are fluctuations in readings then set the frame rate to 250Hz otherwise don’t need for it. Please see the details of “frame rate” and changing the communication interface in Section-7.4 table-11.
Standard output mode of LiDAR should be used instead of PIX mode in the latest firmwares. PIX mode was only required for the firmware versions older than Arducopter V3.6.2.
The default communication of TFmini-Plus is TTL, IIC and TTL uses the same cable, so please set TFmini-Plus to IIC communication first, see detail commands in product manual.
We take two TFmini-Plus as an example (for obstacle) avoidance in this tutorial and set the address 0x10 and 0x11 separately.
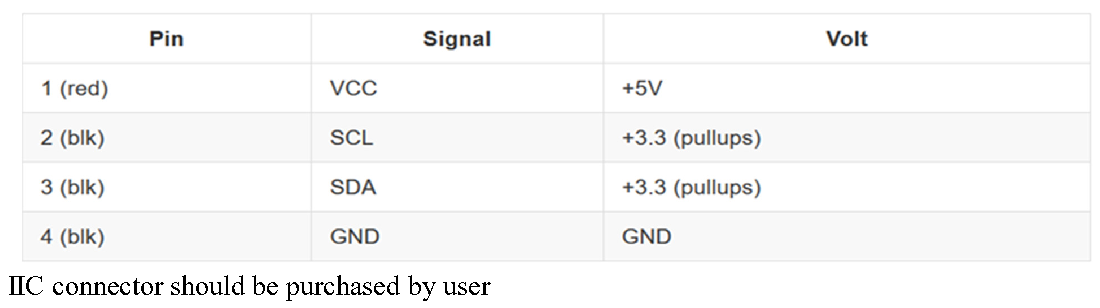
Note: 1. Default cable sequence of TFmini-Plus and PixHawk1 are different, please change it accordingly (SDA and SCL wires need to be interchanged). Look at the pinout of controller, pin configurations are starting from left to right:
2.
3. If TFmini-Plus faces down, please take care the distance between lens and ground should be larger than TFmini-Plus’s blind zone (10cm) 4. If more TFmini-Plus need to be connected (10 LiDARs can be connected), the method is same.
5. Power source should meet the product manual demands:5V±0.5V, larger than 140mA*number of TFmini-Plus
See the connection details in PixHawk1 manual and TFmini-Plus manual, we take example for connecting PixHawk1 flight controller:
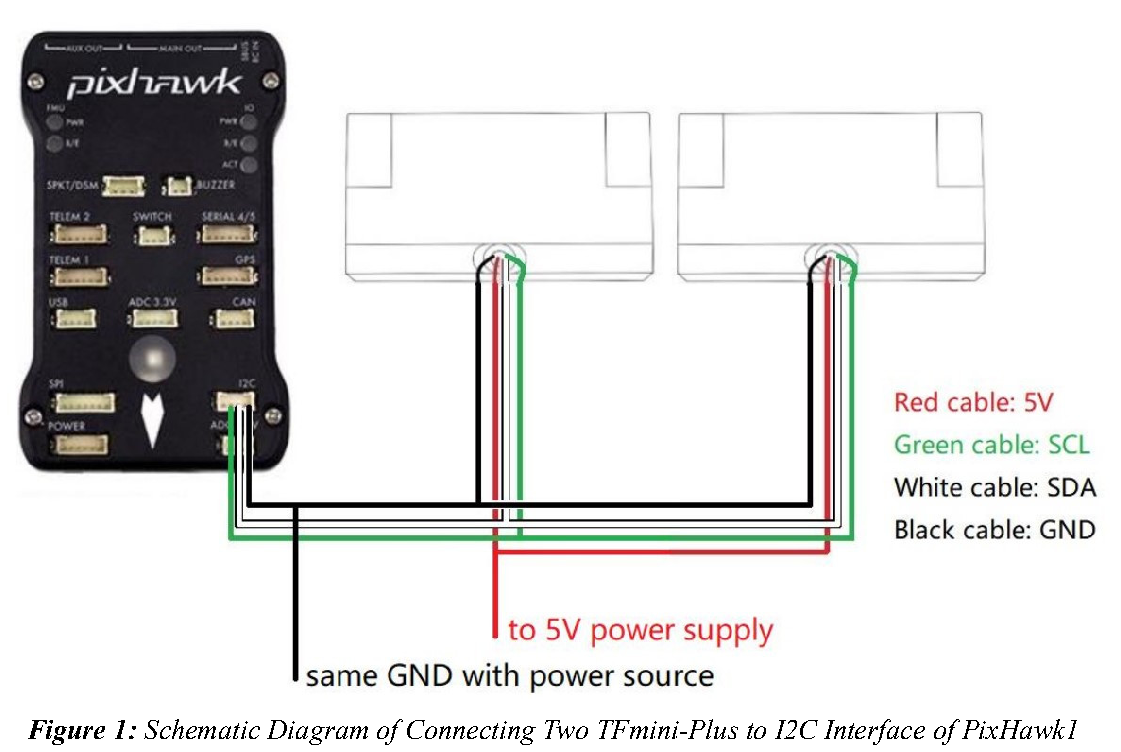
3. Parameters settings (Obstacle Avoidance):
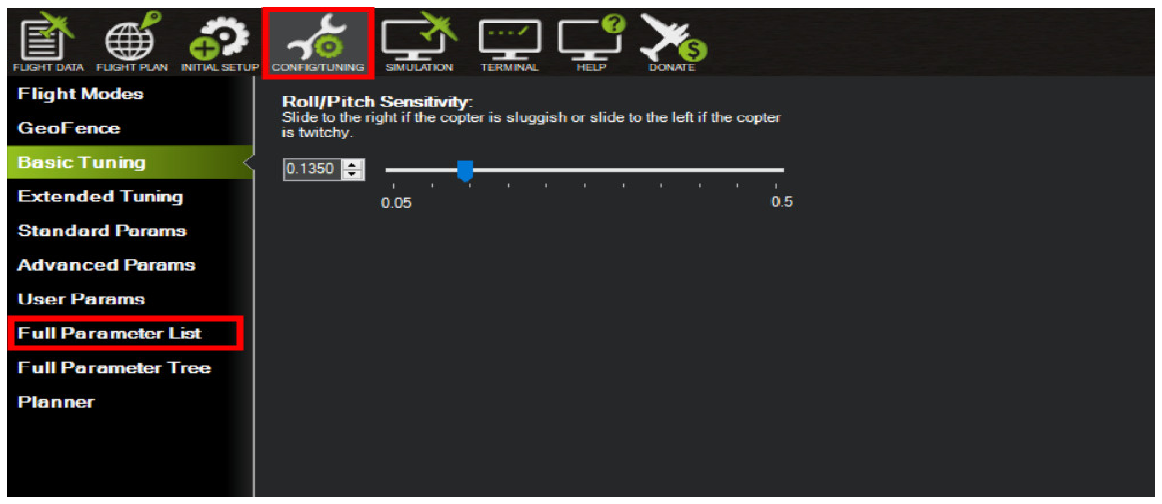
Connect the flight control board to Mission Planar. Select [CONFIG/TUNING] and then click on [Full Parameter List] in the left from the below bar. Find and modify the following parameters:
Common settings: AVOID_ENABLE= 3 [if 3 = UseFence and UseProximitySensor doesn’t work in IIC then choose 2 = UseProximitySensor] AVOID_MARGIN=4 PRX_TYPE=4 Settings for first TFmini-Plus: RNGFND1_ADDR=16 [Address of #1 TFmini-Plus in decimal] RNGFND1_MAX_CM=400 [It could be changed according to real application requirement but should be smaller than effective measure range of LiDAR, unit is cm] RNGFND1_MIN_CM=30 [It could be changed according to real application requirement and should be larger than LiDAR non-detection zone, unit is cm] RNGFND1_ORIENT=0 [#1 TFmini-Plus real orientation] RNGFND1_TYPE = 25 [TFmini-Plus IIC same as TFmini-S IIC] Settings for second TFmini-Plus: RNGFND2_ADDR=17 [Address of #2 TFmini-Plus in decimal] RNGFND2_MAX_CM=400 RNGFND2_MIN_CM=30 RNGFND2_ORIENT=1 [#2 TFmini-Plus real orientation] RNGFND2_TYPE=25 [TFmini-Plus IIC same as TFmini-S IIC] Upon setting of these parameters, click [Write Params] on the right of mission planner to finish. After writing the parameters you need to power off the controller and then turn it on to apply the setting changes.
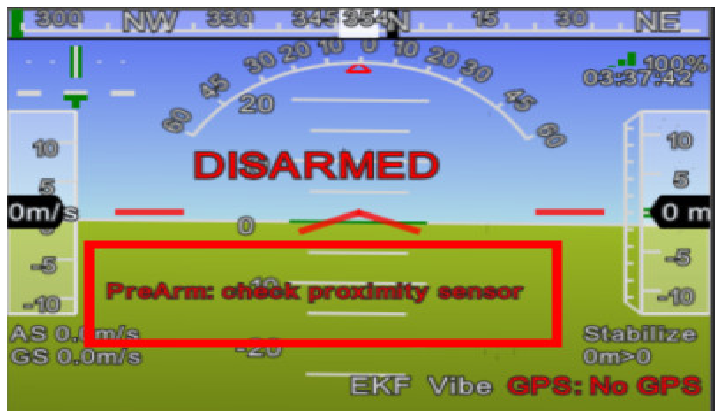
If the error message “PreArm: check the proximity sensor” appears, please check if the connection is correct, the power supply is normal and have you restarted the controller. Also check it whether you have changed the mode from Standard mode to Pix mode while the firmware is 3.6.2 or higher if yes then the same error will encounter.
How to see the target distance from the LiDAR: press Ctrl+F button in keyboard, the following window will pop out:
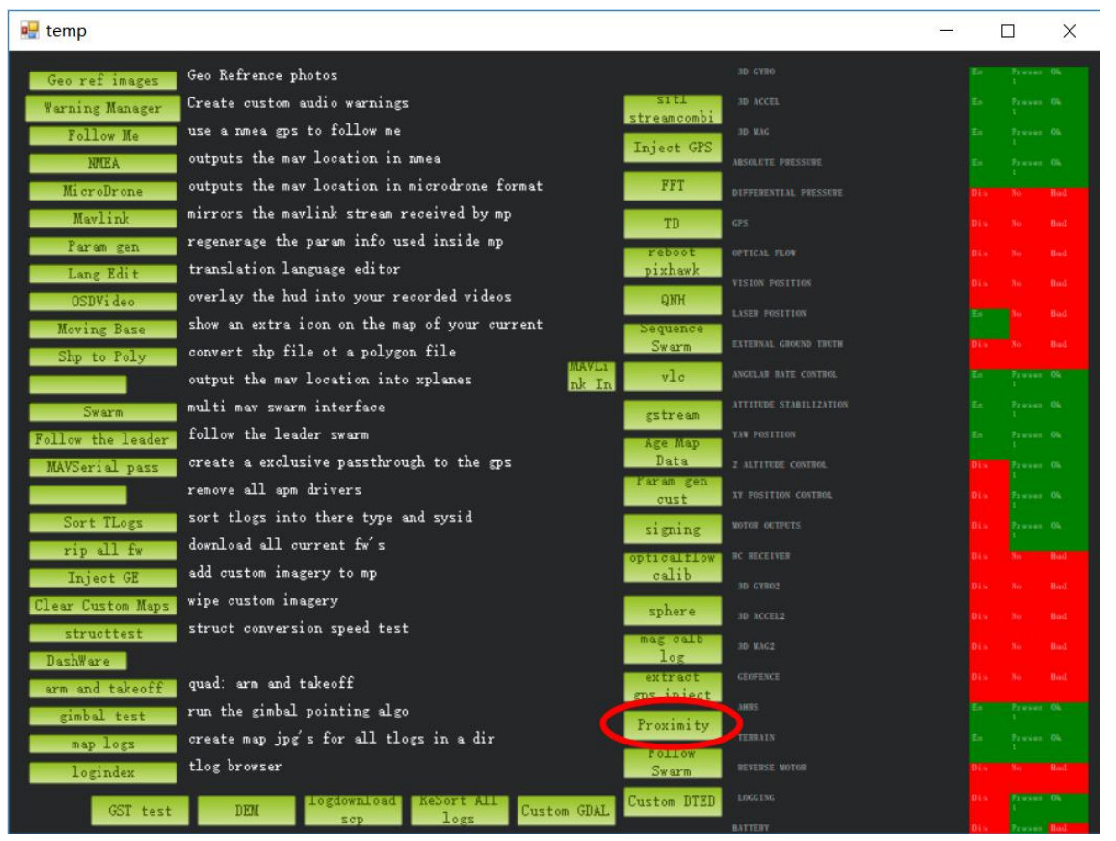
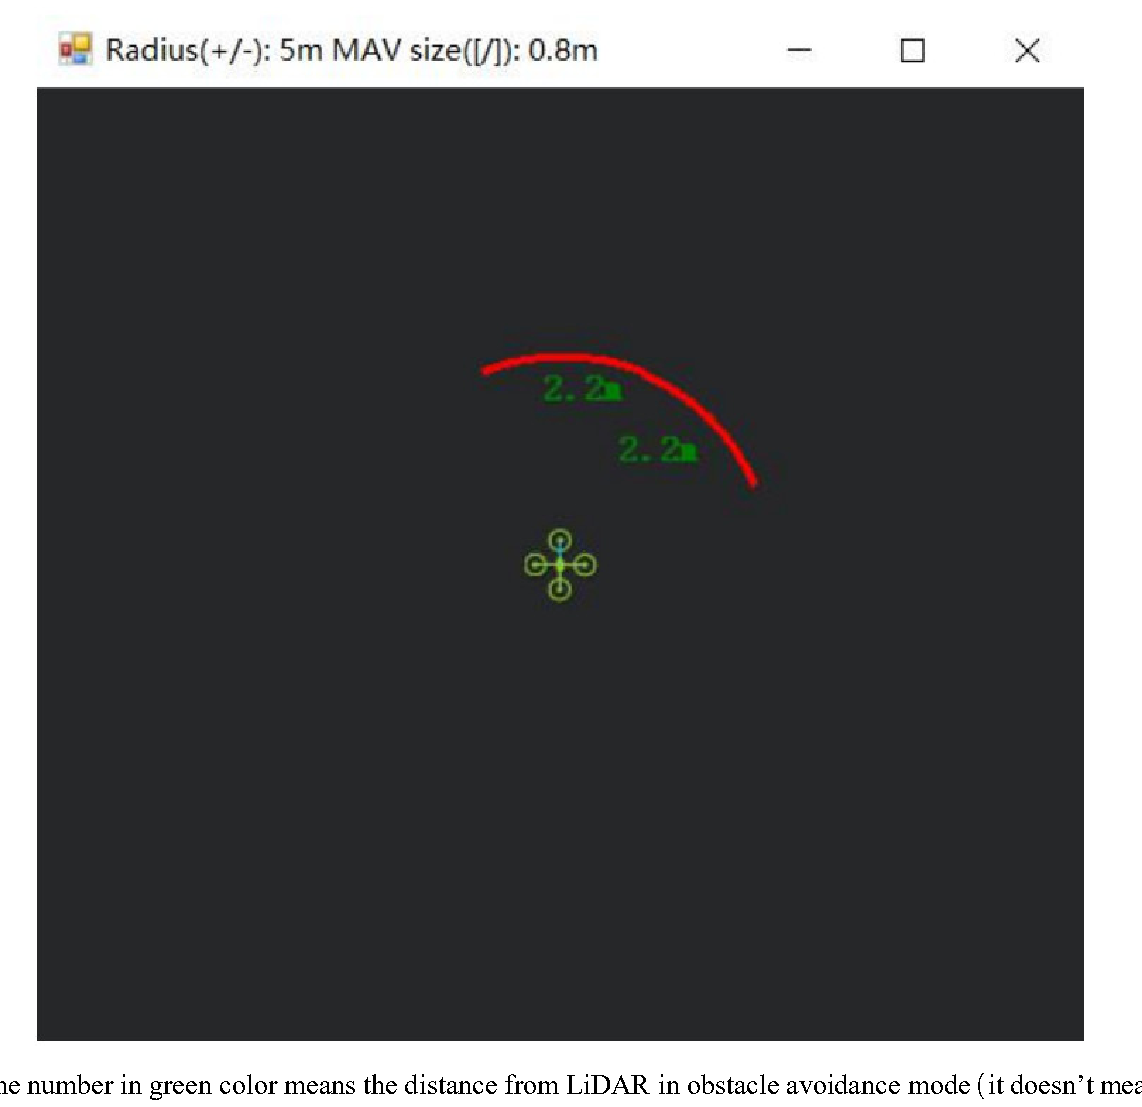
Tn the real time distance from LiDAR and will not be influenced in Mission Planner. The mission planner version at the time of writing this tutorial was v1.3.69.
4. Parameters settings (Altitude Hold):
Connect the flight control board to Mission Planar. Select [CONFIG/TUNING] and then click on [Full Parameter List] in the left from the below bar. Find and modify the following parameters:
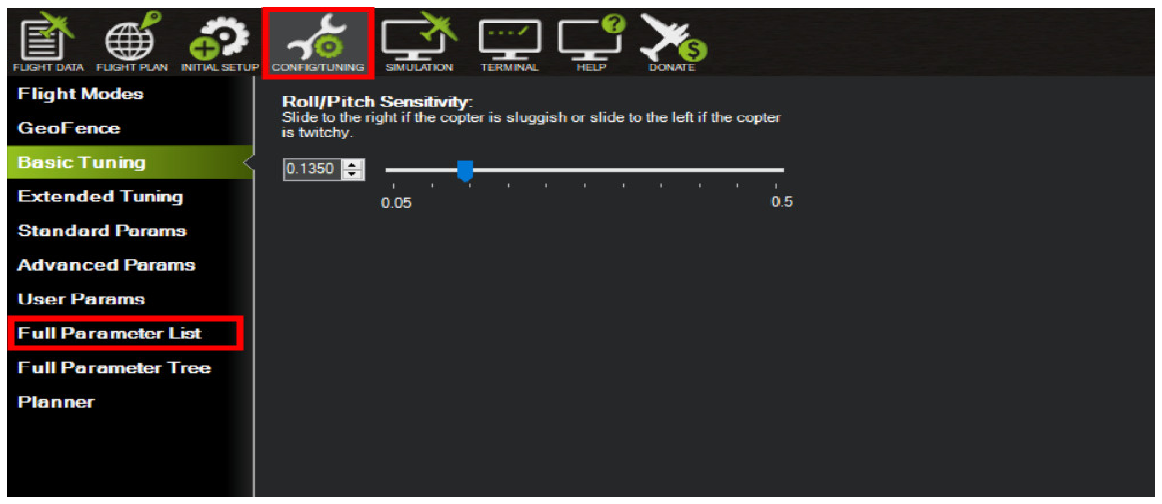
Note: If RNGFND1 and RNGFND2 are already configured then use RNGFND3 or other as Altitude Hold Sensor.
RNGFND1_ADDR=18 RNGFND3_TYPE = 25 [TFmini-Plus IIC option] RNGFND3_MIN_CM = 30 [It could be changed according to real application requirement and should be greater LiDAR than non-detection zone, unit is cm] RNGFND3_MAX_CM = 300 [It could be changed according to real demands but should be smaller than effective measure range of LiDAR, unit is cm] RNGFND3_GNDCLEAR = 15 [expressed in cm, depending upon mounting height of the module and should be greater LiDAR than non-detection zone] RNGFND3_ORIENT=25 [facing down] Upon setting of these parameters, click [Write Params] on the right of mission planner to finish. After writing the parameters you need to power off the controller and then turn it on to apply the setting changes.
If the error message “Bad LiDAR Health” appears, please check if the connection is correct, the power supply is normal and have you restarted the controller? Also check it whether you have changed the mode from Standard mode to Pix mode while the firmware is 3.6.2 or higher if yes then the same error will encounter.
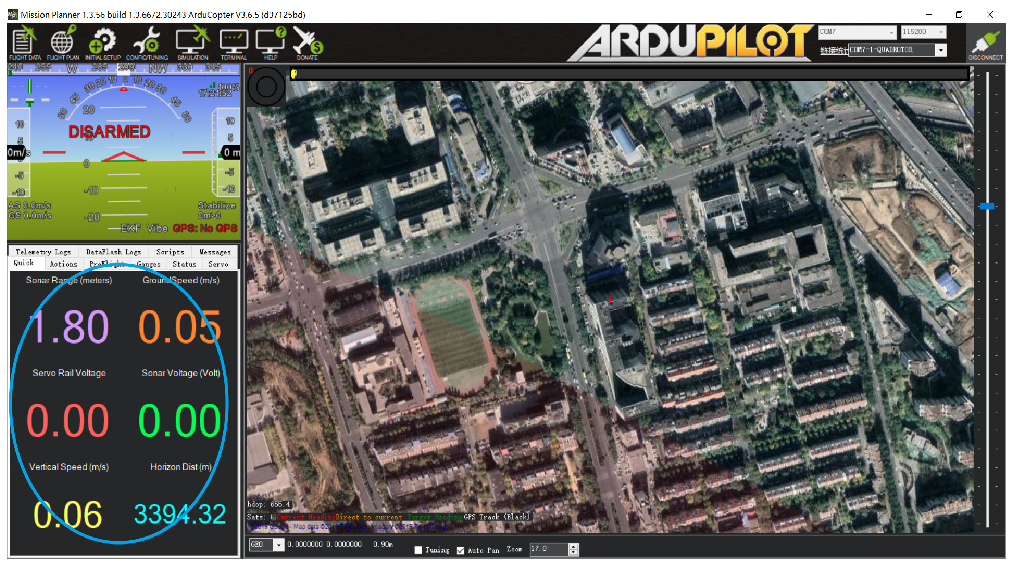
the following picture:
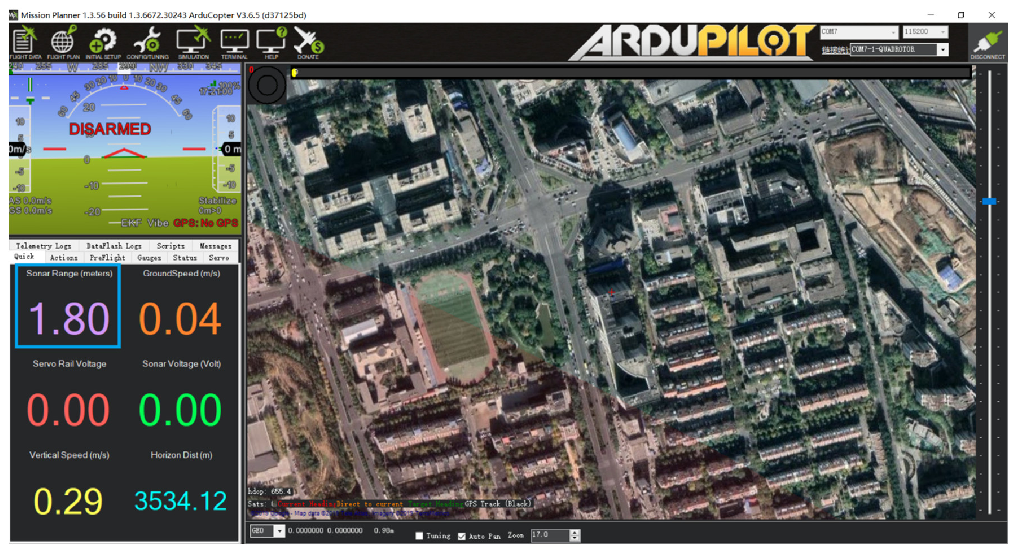
Select option sonarrange, see following picture:
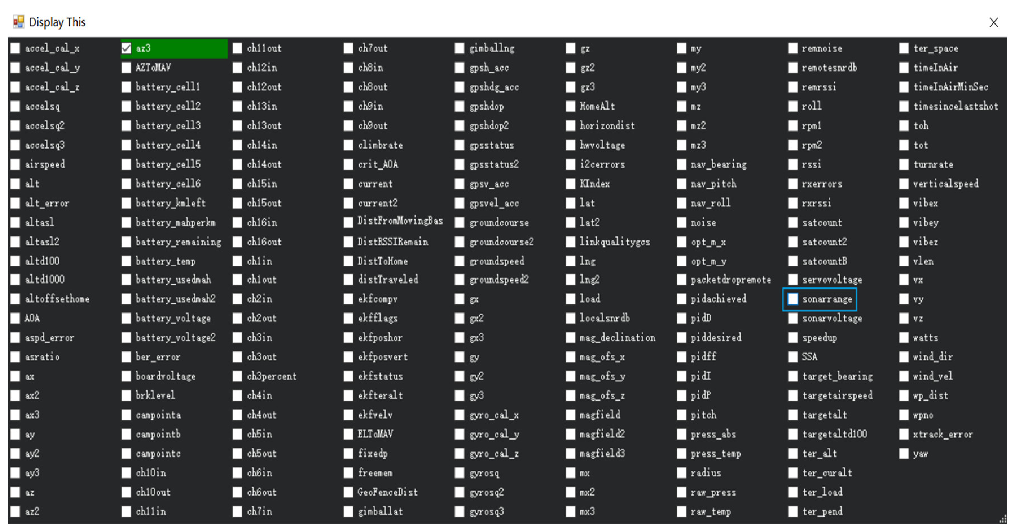
picture: